

24
2 Robust Filtering for Multi-model Jumping System
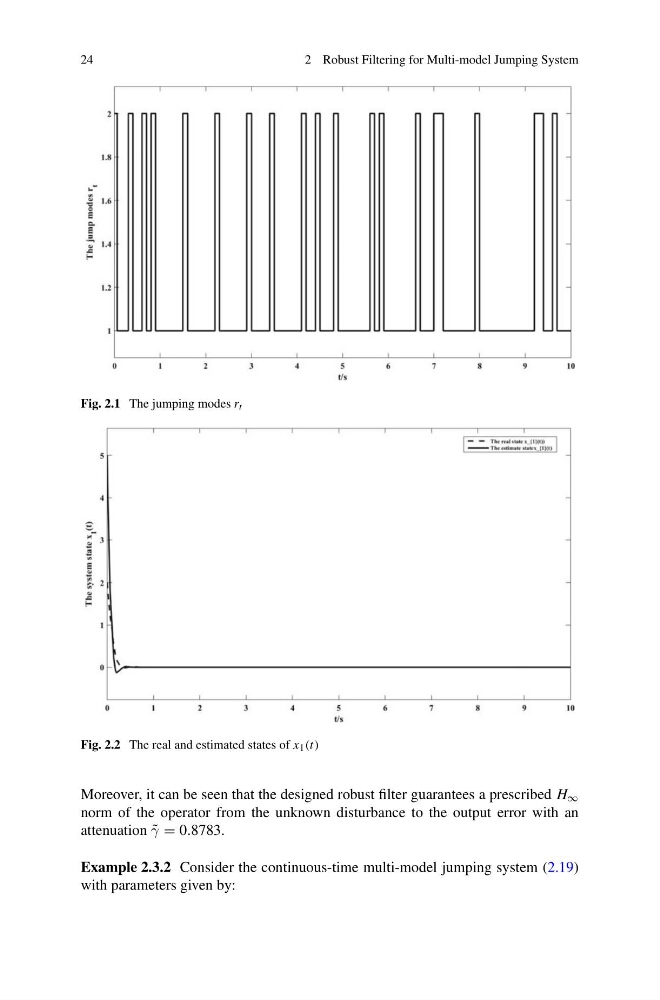
Fig. 2.1 The jumping modes r t
Fig. 2.2 The real and estimated states of x 1 (t)
Moreover, it can be seen that the designed robust filter guarantees a prescribed H ∞
norm of the operator from the unknown disturbance to the output error with an
attenuation ˜
γ = 0.8783.
Example 2.3.2 Consider the continuous-time multi-model jumping system (2.19)
with parameters given by: