

9.2 Design of RFD Observer
163
9.2 Design of RFD Observer
For minimizing the impacts of disturbances to the residual, the H ∞ filtering issue
is formulated when f (t) = 0. It devises the observer parameter H i which can
make the error dynamic multi-model jumping system (9.13) be stochastically stable and for all nonzero ω(t) ∈ L 2 [0, ∞], it follows that E{
T
0 r
T
eo (t)r eo (t)dt} ≤
λ
2 E{
T
0 ω
T
(t)ω(t)dt}| f (t)=0 .
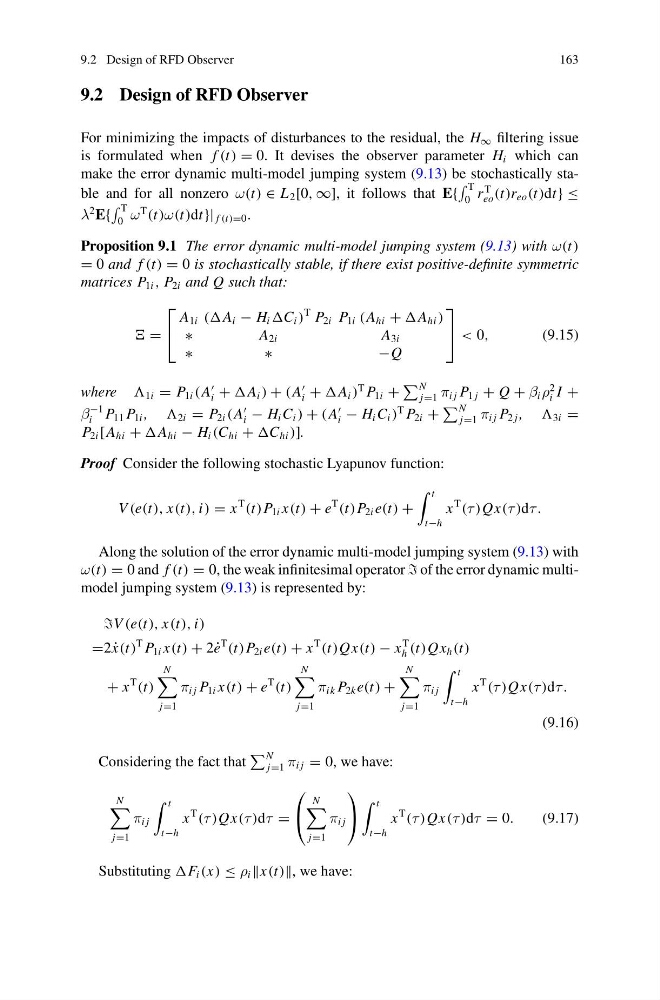
Proposition 9.1 The error dynamic multi-model jumping system (9.13) with ω(t)
= 0 and f (t) = 0 is stochastically stable, if there exist positive-definite symmetric
matrices P 1i , P 2i and Q such that:
=
⎡
⎣
A 1i (A i − H i C i )
T P 2i P 1i (A hi + A hi )
∗
A 2i
A 3i
∗
∗
− Q
⎤
⎦ < 0,
(9.15)
where 1i = P 1i (A
i + A i ) + (A
i + A i )
T P 1i +
N
j=1 π i j P 1 j + Q + β i ρ
2
i I +
β
−1
i P 11 P 1i , 2i = P 2i (A
i − H i C i ) + (A
i − H i C i )
T P 2i +
N
j=1 π i j P 2 j , 3i =
P 2i [A hi + A hi − H i (C hi + C hi )].
Proof Consider the following stochastic Lyapunov function:
V (e(t), x(t), i) = x
T
(t)P 1i x(t) + e
T
(t)P 2i e(t) +
t
t−h
x
T
(τ )Qx(τ )dτ .
Along the solution of the error dynamic multi-model jumping system (9.13) with
ω(t) = 0 and f (t) = 0, the weak infinitesimal operator of the error dynamic multimodel jumping system (9.13) is represented by:
V (e(t), x(t), i)
=2 ˙
x(t)
T P 1i x(t) + 2 ˙
e
T
(t)P 2i e(t) + x
T
(t)Qx(t) − x
T
h (t)Qx h (t)
+ x
T
(t)
N
j=1
π i j P 1i x(t) + e
T
(t)
N
j=1
π ik P 2k e(t) +
N
j=1
π i j
t
t−h
x
T
(τ )Qx(τ )dτ .
(9.16)
Considering the fact that
N
j=1 π i j = 0, we have:
N
j=1
π i j
t
t−h
x
T
(τ )Qx(τ )dτ =
⎛
⎝
N
j=1
π i j
⎞
⎠
t
t−h
x
T
(τ )Qx(τ )dτ = 0.
(9.17)
Substituting F i (x) ≤ ρ i x(t), we have: