

144
8 Filtering-Based Robust Fault Detection of Fuzzy Multi-model Jumping System
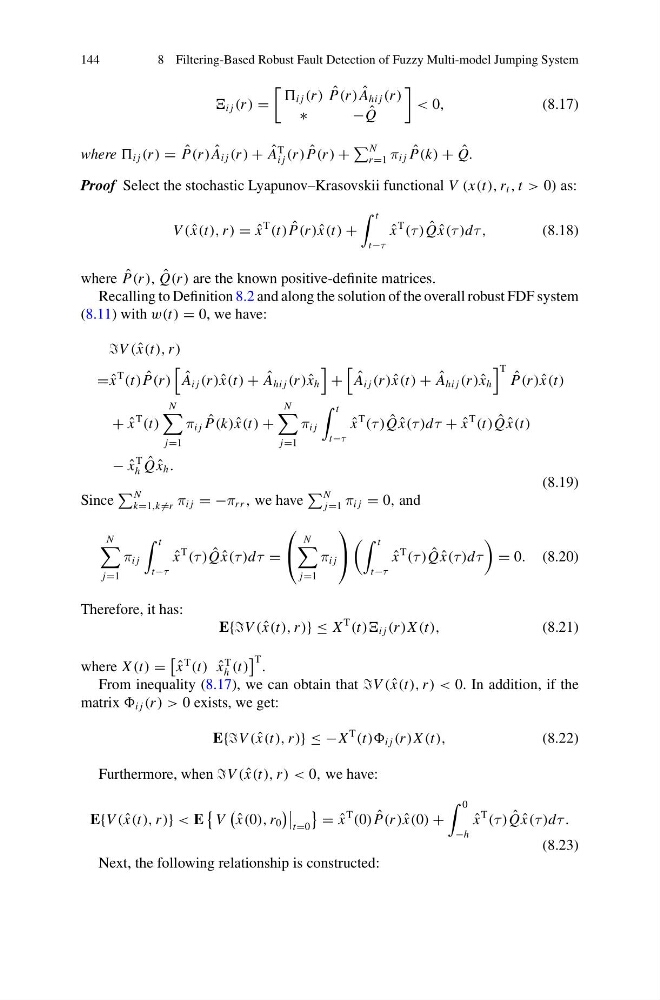
i j (r ) =
i j (r ) ˆ
P(r ) ˆ
A hi j (r )
∗
− ˆ
Q
< 0,
(8.17)
where i j (r ) = ˆ
P(r ) ˆ
A i j (r ) + ˆ
A
T
i j (r ) ˆ
P(r ) +
N
r =1 π i j ˆ
P(k) + ˆ
Q.
Proof Select the stochastic Lyapunov–Krasovskii functional V (x(t), r t , t > 0) as:
V ( ˆ
x(t), r ) = ˆ
x
T
(t) ˆ
P(r ) ˆ
x(t) +
t
t−τ
ˆ
x
T
(τ ) ˆ
Q ˆ
x(τ )dτ ,
(8.18)
where ˆ
P(r ), ˆ
Q(r ) are the known positive-definite matrices.
Recalling to Definition 8.2 and along the solution of the overall robust FDF system
(8.11) with w(t) = 0, we have:
V ( ˆ
x(t), r )
= ˆ
x
T
(t) ˆ
P(r )
ˆ
A i j (r ) ˆ
x(t) + ˆ
A hi j (r ) ˆ
x h
+
ˆ
A i j (r ) ˆ
x(t) + ˆ
A hi j (r ) ˆ
x h
T ˆ
P(r ) ˆ
x(t)
+ ˆ
x
T
(t)
N
j=1
π i j ˆ
P(k) ˆ
x(t) +
N
j=1
π i j
t
t−τ
ˆ
x
T
(τ ) ˆ
Q ˆ
x(τ )dτ + ˆ
x
T
(t) ˆ
Q ˆ
x(t)
− ˆ
x
T
h
ˆ
Q ˆ
x h .
(8.19)
Since
N
k=1,k =r π i j = −π rr , we have
N
j=1 π i j = 0, and
N
j=1
π i j
t
t−τ
ˆ
x
T
(τ ) ˆ
Q ˆ
x(τ )dτ =
⎛
⎝
N
j=1
π i j
⎞
⎠
t
t−τ
ˆ
x
T
(τ ) ˆ
Q ˆ
x(τ )dτ
= 0. (8.20)
Therefore, it has:
E{{V ( ˆ
x(t), r )} ≤ X
T
(t)) i j (r )X (t),
(8.21)
where X (t) =
ˆ
x
T
(t) ˆ
x
T
h (t)
T .
From inequality (8.17), we can obtain that V ( ˆ
x(t), r ) < 0. In addition, if the
matrix i j (r ) > 0 exists, we get:
E{{V ( ˆ
x(t), r )} ≤ −X
T
(t)) i j (r )X (t),
(8.22)
Furthermore, when V ( ˆ
x(t), r ) < 0, we have:
E{V ( ˆ
x(t), r )} < E
V
ˆ
x(0), r 0
t=0
= ˆ
x
T
(0) ˆ
P(r ) ˆ
x(0) +
0
−h
ˆ
x
T
(τ ) ˆ
Q ˆ
x(τ )dτ .
(8.23)
Next, the following relationship is constructed: