

8.1 Robust FDF Design for Fuzzy Multi-model Jumping System
143
J e = sup
w(t)∈L 2
r F (t) − r f (t)
2E
w(t) 2
=
sup
w(t)∈L 2 w(t) =0
r e f (t) 2E
w(t) 2
< γ,
(8.12)
where r e f (t) 2,E ≤
E
∞
0 r
T
e f (t)r e f (t)dt
, w(t) 2 ≤
∞
0 w T (t)w(t)dt
.
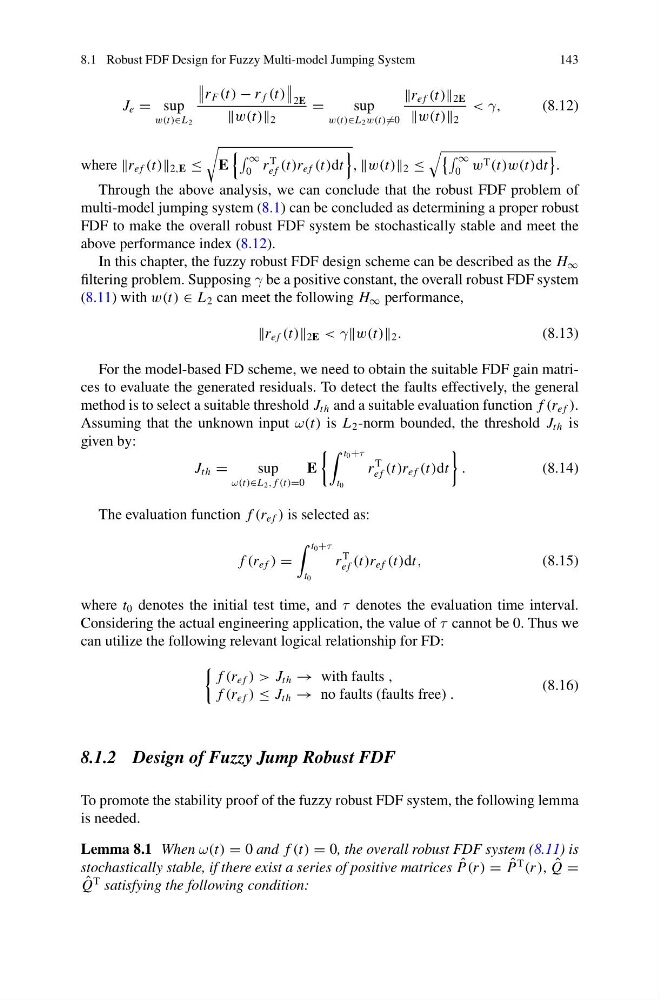
Through the above analysis, we can conclude that the robust FDF problem of
multi-model jumping system (8.1) can be concluded as determining a proper robust
FDF to make the overall robust FDF system be stochastically stable and meet the
above performance index (8.12).
In this chapter, the fuzzy robust FDF design scheme can be described as the H ∞
filtering problem. Supposing γ be a positive constant, the overall robust FDF system
(8.11) with w(t) ∈ L 2 can meet the following H ∞ performance,
r e f (t) 2E < γw(t) 2 .
(8.13)
For the model-based FD scheme, we need to obtain the suitable FDF gain matrices to evaluate the generated residuals. To detect the faults effectively, the general
method is to select a suitable threshold J th and a suitable evaluation function f (r e f ).
Assuming that the unknown input ω(t) is L 2 -norm bounded, the threshold J th is
given by:
J th =
sup
ω(t)∈L 2 , f (t)=0
E
t 0 +τ
t 0
r
T
e f (t)r e f (t)dt
.
(8.14)
The evaluation function f (r e f ) is selected as:
f (r e f ) =
t 0 +τ
t 0
r
T
e f (t)r e f (t)dt,
(8.15)
where t 0 denotes the initial test time, and τ denotes the evaluation time interval.
Considering the actual engineering application, the value of τ cannot be 0. Thus we
can utilize the following relevant logical relationship for FD:
f (r e f ) > J th → with faults ,
f (r e f ) ≤ J th → no faults (faults free) .
(8.16)
8.1.2 Design of Fuzzy Jump Robust FDF
To promote the stability proof of the fuzzy robust FDF system, the following lemma
is needed.
Lemma 8.1 When ω(t) = 0 and f (t) = 0, the overall robust FDF system (8.11) is
stochastically stable, if there exist a series of positive matrices ˆ
P(r ) = ˆ
P
T
(r ), ˆ
Q =
ˆ
Q
T satisfying the following condition: