

7.2 FDO Design for Fuzzy Multi-model Jumping System
133
5i j (r ) =
0
−
C h j (r ) + C h j (r )
T
,
6i j (r ) = 4γ I −
D f i (r ) + D f j (r )
T −
D f i (r ) + D f j (r )
.
Moreover, the parameter matrices of the FDO can be obtained as H i (r ) =
P
−1
2 (r )H i (r ).
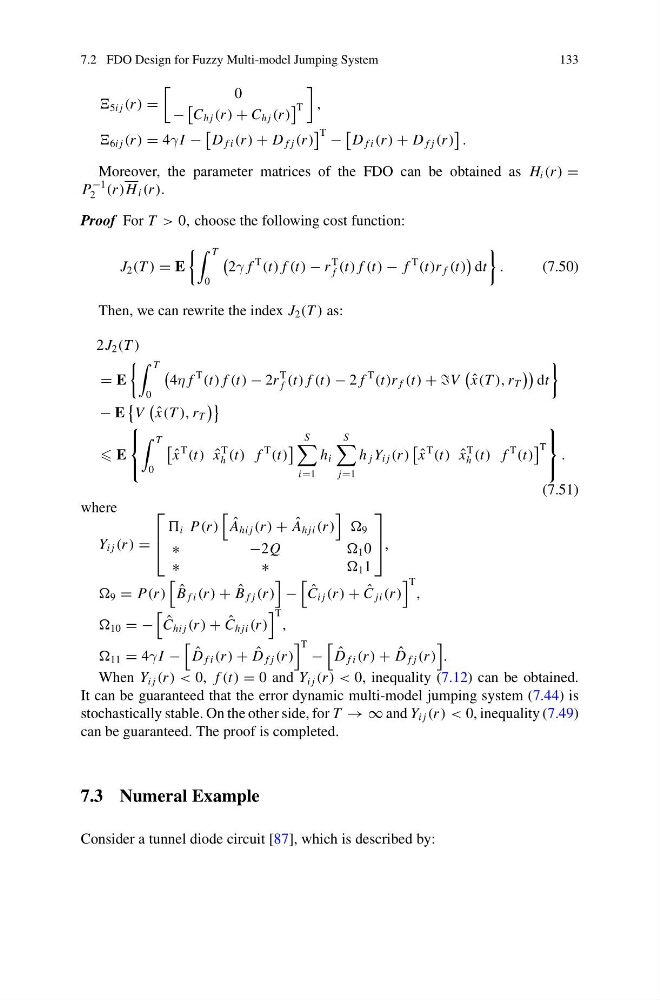
Proof For T > 0, choose the following cost function:
J 2 (T ) = E
T
0
2γ f
T
(t) f (t) − r
T
f (t) f (t) − f
T
(t)r f (t)
dt
.
(7.50)
Then, we can rewrite the index J 2 (T ) as:
2J 2 (T )
= E
T
0
4η f
T
(t) f (t) − 2r
T
f (t) f (t) − 2 f
T
(t)r f (t) + +V
ˆ
x(T ), r T
dt
− E
V
ˆ
x(T ), r T
E
⎧
⎨
⎩
T
0
ˆ
x
T
(t) ˆ
x
T
h (t) f
T
(t)
S
i=1
h i
S
j=1
h j Y i j (r )
ˆ
x
T
(t) ˆ
x
T
h (t) f
T
(t)
T
⎫
⎬
⎭
.
(7.51)
where
Y i j (r ) =
⎡
⎢
⎣
i P(r )
ˆ
A hi j (r ) + ˆ
A h ji (r )
9
∗
− 2Q
1 0
∗
∗
1 1
⎤
⎥
⎦,
9 = P(r )
ˆ
B f i (r ) + ˆ
B f j (r )
−
ˆ
C i j (r ) + ˆ
C ji (r )
T
,
10 = −
ˆ
C hi j (r ) + ˆ
C h ji (r )
T
,
11 = 4γ I −
ˆ
D f i (r ) + ˆ
D f j (r )
T −
ˆ
D f i (r ) + ˆ
D f j (r )
.
When Y i j (r ) < 0, f (t) = 0 and Y i j (r ) < 0, inequality (7.12) can be obtained.
It can be guaranteed that the error dynamic multi-model jumping system (7.44) is
stochastically stable. On the other side, for T → ∞ and Y i j (r ) < 0, inequality (7.49)
can be guaranteed. The proof is completed.
7.3 Numeral Example
Consider a tunnel diode circuit [87], which is described by: