

132
7 Observer-Based Robust Fault Detection for Fuzzy Multi-model Jumping System
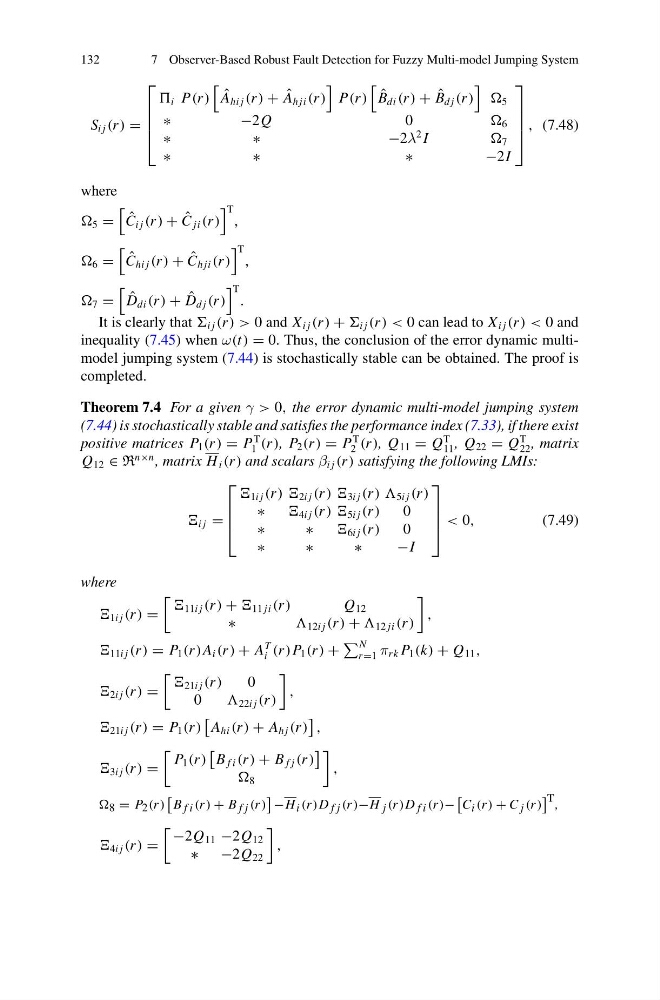
S i j (r ) =
⎡
⎢
⎢
⎢
⎣
i P(r )
ˆ
A hi j (r ) + ˆ
A h ji (r )
P(r )
ˆ
B di (r ) + ˆ
B d j (r )
5
∗
− 2Q
0
6
∗
∗
− 2λ
2 I
7
∗
∗
∗
− 2I
⎤
⎥
⎥
⎥
⎦
, (7.48)
where
5 =
ˆ
C i j (r ) + ˆ
C ji (r )
T
,
6 =
ˆ
C hi j (r ) + ˆ
C h ji (r )
T
,
7 =
ˆ
D di (r ) + ˆ
D d j (r )
T
.
It is clearly that i j (r ) > 0 and X i j (r ) + i j (r ) < 0 can lead to X i j (r ) < 0 and
inequality (7.45) when ω(t) = 0. Thus, the conclusion of the error dynamic multimodel jumping system (7.44) is stochastically stable can be obtained. The proof is
completed.
Theorem 7.4 For a given γ > 0, the error dynamic multi-model jumping system
(7.44) is stochastically stable and satisfies the performance index (7.33), if there exist
positive matrices P 1 (r ) = P
T
1 (r ), P 2 (r ) = P
T
2 (r ), Q 11 = Q
T
11 , Q 22 = Q
T
22 , matrix
Q 12 ∈ R
n×n , matrix H i (r ) and scalars β i j (r ) satisfying the following LMIs:
i j =
⎡
⎢
⎢
⎣
1i j (r ) ) 2i j (r ) ) 3i j (r ) ) 5i j (r )
∗
4i j (r ) ) 5i j (r )
0
∗
∗
6i j (r )
0
∗
∗
∗
−I
⎤
⎥
⎥
⎦ < 0,
(7.49)
where
1i j (r ) =
11i j (r ) + 11 ji (r )
Q 12
∗
12i j (r ) + 12 ji (r )
,
11i j (r ) = P 1 (r )A i (r ) + A
T
i (r )P 1 (r ) +
N
r =1 π rk P 1 (k) + Q 11 ,
2i j (r ) =
21i j (r )
0
0
22i j (r )
,
21i j (r ) = P 1 (r )
A hi (r ) + A h j (r )
,
3i j (r ) =
P 1 (r )
B f i (r ) + B f j (r )
8
,
8 = P 2 (r )
B f i (r ) + B f j (r )
−H i (r )D f j (r )−H j (r )D f i (r )−
C i (r ) + C j (r )
T ,
4i j (r ) =
−2Q 11 −2Q 12
∗ −2Q 22
,