

134
7 Observer-Based Robust Fault Detection for Fuzzy Multi-model Jumping System
⎧
⎪ ⎪ ⎪ ⎨
⎪ ⎪ ⎪ ⎩
˙
x 1 (t) = −0.1x 1 (t) −
α(i) + α(i)
C
x
2
1 (t)
x 1 (t) + 10x 2 (t),
L ˙
x 2 (t) = −x 1 (t) − Rx 2 (t) + 0.1ω(t),
y(t) = J x(t) + 0.1ω(t),
(7.52)
where x(t) =
x 1 (t)
x 2 (t)
are the states, ω(t) is the unknown input, y(t) is the
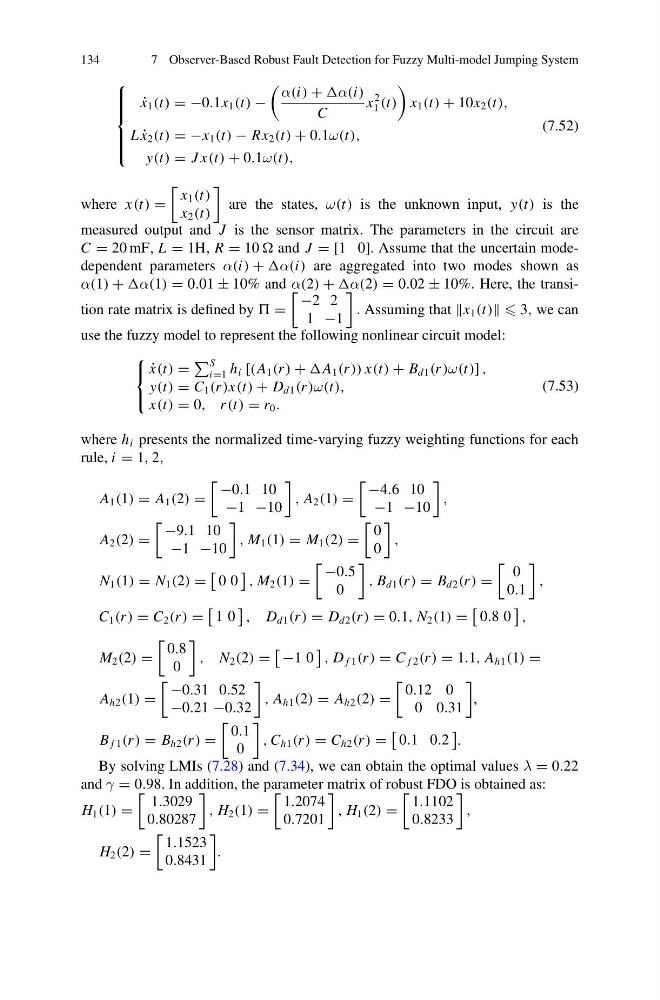
measured output and J is the sensor matrix. The parameters in the circuit are
C = 20 mF, L = 1H, R = 10 and J = [1 0]. Assume that the uncertain modedependent parameters α(i) + α(i) are aggregated into two modes shown as
α(1) + α(1) = 0.01 ± 10% and α(2) + α(2) = 0.02 ± 10%. Here, the transition rate matrix is defined by =
−2 2
1 −1
. Assuming that x 1 (t) 3, we can
use the fuzzy model to represent the following nonlinear circuit model:
⎧
⎨
⎩
˙
x(t) =
S
i=1 h i [(A 1 (r ) + A 1 (r )) x(t) + B d1 (r )ω(t)] ,
y(t) = C 1 (r )x(t) + D d1 (r )ω(t),
x(t) = 0, r (t) = r 0 .
(7.53)
where h i presents the normalized time-varying fuzzy weighting functions for each
rule, i = 1, 2,
A 1 (1) = A 1 (2) =
−0.1 10
−1 −10
, A 2 (1) =
−4.6 10
−1 −10
,
A 2 (2) =
−9.1 10
−1 −10
, M 1 (1) = M 1 (2) =
0
0
,
N 1 (1) = N 1 (2) =
0 0
, M 2 (1) =
−0.5
0
, B d1 (r ) = B d2 (r ) =
0
0.1
,
C 1 (r ) = C 2 (r ) =
1 0
, D d1 (r ) = D d2 (r ) = 0.1, N 2 (1) =
0.8 0
,
M 2 (2) =
0.8
0
, N 2 (2) =
−1 0
, D f 1 (r ) = C f 2 (r ) = 1.1, A h1 (1) =
A h2 (1) =
−0.31 0.52
−0.21 −0.32
, A h1 (2) = A h2 (2) =
0.12 0
0 0.31
,
B f 1 (r ) = B h2 (r ) =
0.1
0
, C h1 (r ) = C h2 (r ) =
0.1 0.2
.
By solving LMIs (7.28) and (7.34), we can obtain the optimal values λ = 0.22
and γ = 0.98. In addition, the parameter matrix of robust FDO is obtained as:
H 1 (1) =
1.3029
0.80287
, H 2 (1) =
1.2074
0.7201
, H 1 (2) =
1.1102
0.8233
,
H 2 (2) =
1.1523
0.8431
.