

8 Beam-based Correction and Optimization for Accelerators
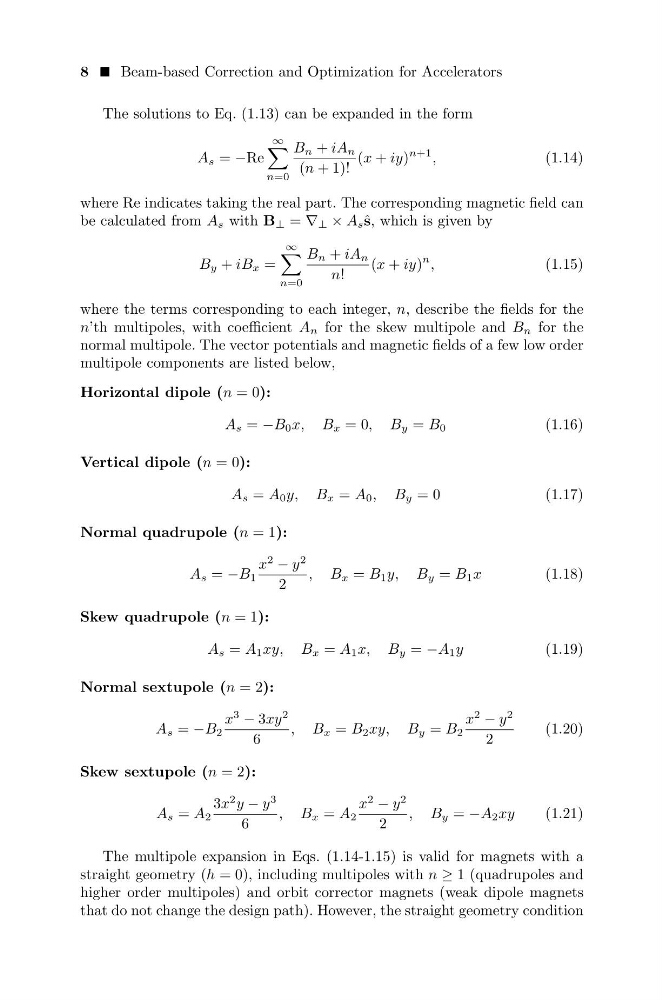
The solutions to Eq. (1.13) can be expanded in the form
A s = −Re
∞
n=0
B n + iA n
(n + 1)!
(x + iy)
n+1 ,
(1.14)
where Re indicates taking the real part. The corresponding magnetic field can
be calculated from A s with B ⊥ = ∇ ⊥ × A s ˆ s, which is given by
B y + iB x =
∞
n=0
B n + iA n
n!
(x + iy)
n ,
(1.15)
where the terms corresponding to each integer, n, describe the fields for the
n’th multipoles, with coefficient A n for the skew multipole and B n for the
normal multipole. The vector potentials and magnetic fields of a few low order
multipole components are listed below,
Horizontal dipole (n = 0):
A s = −B 0 x, B x = 0, B y = B 0
(1.16)
Vertical dipole (n = 0):
A s = A 0 y, B x = A 0 , B y = 0
(1.17)
Normal quadrupole (n = 1):
A s = −B 1
x
2 − y
2
2
, B x = B 1 y, B y = B 1 x
(1.18)
Skew quadrupole (n = 1):
A s = A 1 xy, B x = A 1 x, B y = −A 1 y
(1.19)
Normal sextupole (n = 2):
A s = −B 2
x
3 − 3xy
2
6
, B x = B 2 xy, B y = B 2
x
2 − y
2
2
(1.20)
Skew sextupole (n = 2):
A s = A 2
3x
2 y − y
3
6
, B x = A 2
x
2 − y
2
2
, B y = −A 2 xy
(1.21)
The multipole expansion in Eqs. (1.14-1.15) is valid for magnets with a
straight geometry (h = 0), including multipoles with n ≥ 1 (quadrupoles and
higher order multipoles) and orbit corrector magnets (weak dipole magnets
that do not change the design path). However, the straight geometry condition