

2.2 Continuous-Discrete Extended Kalman Filter
As described in the previous section, the Kalman filter addresses the general problem
of trying to estimate the state of a process that is governed by a linear differential
equation system. In non-linear dynamic systems, the process model or the measurement model cannot be determined with multiplication of vectors and matrices. For
such systems, a linearization should be performed. The linearization can be
performed by different methods. The essential difference among different versions
of the Kalman filters (extended Kalman filter, unscented Kalman filter and ensemble
Kalman filter) consists in how they calculate the estimation error. A Kalman filter
that linearizes about the current mean and covariance is referred to as an extended
Kalman filter (EKF). A non-linear dynamic system can be described by the following differential equation:
dx t
ð Þ
dt
¼ f x t
ð Þ, u t
ð Þ
ð
Þþw t
ð Þ
ð9Þ
With discrete measurements that are:
z k
½ ¼ h x t k
½
À Á
Â
à þ v k
½
ð10Þ
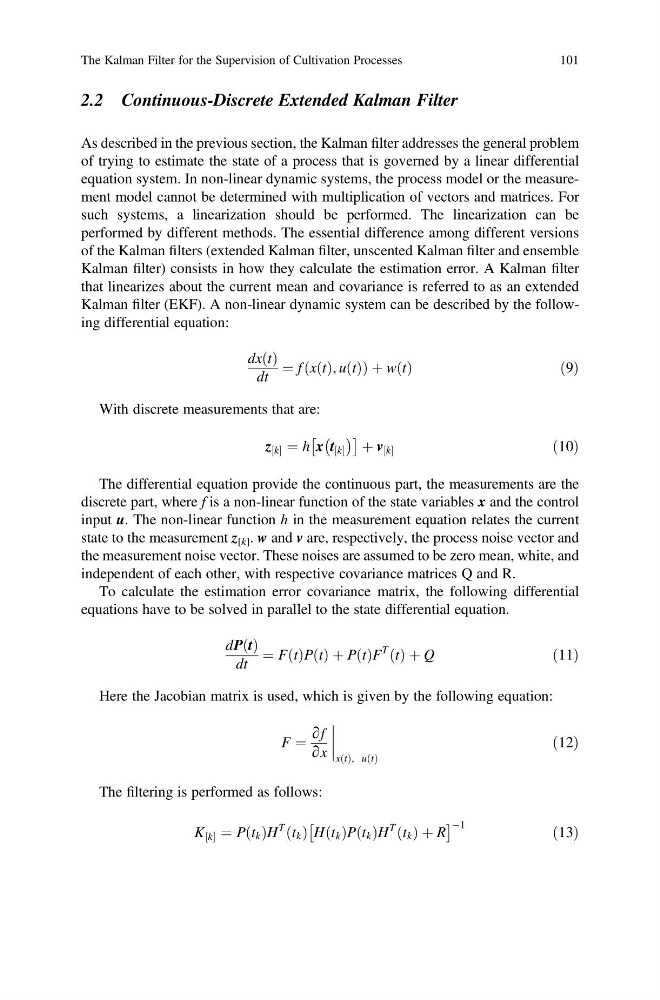
The differential equation provide the continuous part, the measurements are the
discrete part, where f is a non-linear function of the state variables x and the control
input u. The non-linear function h in the measurement equation relates the current
state to the measurement z [k] . w and v are, respectively, the process noise vector and
the measurement noise vector. These noises are assumed to be zero mean, white, and
independent of each other, with respective covariance matrices Q and R.
To calculate the estimation error covariance matrix, the following differential
equations have to be solved in parallel to the state differential equation.
dP t
ð Þ
dt
¼ F t
ð ÞP t
ð Þ þ P t
ð ÞF
T t
ð Þ þ Q
ð11Þ
Here the Jacobian matrix is used, which is given by the following equation:
F ¼
∂f
∂x
x t
ð Þ, u t
ð Þ
ð12Þ
The filtering is performed as follows:
K k
½ ¼ P t k
ð ÞH
T t k
ð Þ H t k
ð ÞP t k
ð ÞH
T t k
ð Þ þ R
Â
à À1
ð13Þ
The Kalman Filter for the Supervision of Cultivation Processes
101