

24
2 Bivector Formalism
remembering that g = det(g ab ). This is easily verified by writing out the left hand
side explicitly, unpacking the summations. Substituting into the left hand side of
(2.28) for g ab from (2.14) gives
abcd g
a0 g
b1 g
c2 g
d3
= abcd ¯
m
a m
b l
c k
d
{( ¯
m
0 m
1
− m
0
¯
m
1 )(l
2 k
3
− l
3 k
2 ) + ( ¯
m
0 m
2
− m
0
¯
m
2 )(k
1 l
3
− k
3 l
1 ) + ( ¯
m
0 m
3
− m
0
¯
m
3 )(l
1 k
2
− l
2 k
1 )
+ ( ¯
m
1 m
2
− m
1
¯
m
2 )(l
0 k
3
− k
0 l
3 ) + ( ¯
m
1 m
3
− m
1
¯
m
3 )(k
0 l
2
− k
2 l
0 ) + ( ¯
m
2 m
3
− m
2
¯
m
3 )(l
0 k
1
− l
1 k
0 )} .
(2.29)
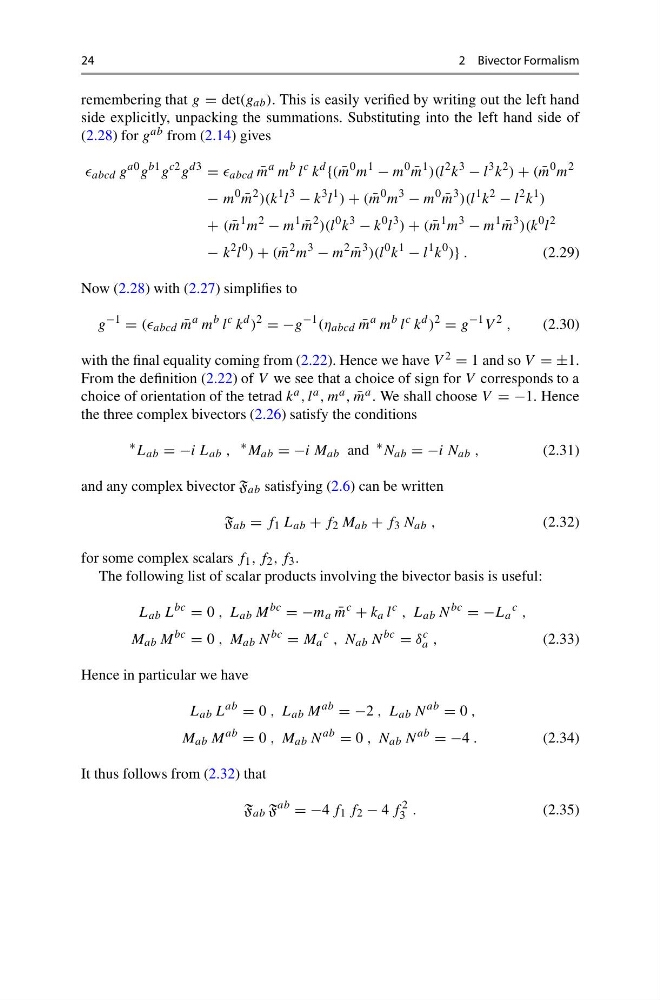
Now (2.28) with (2.27) simplifies to
g
−1
= (( abcd ¯
m
a m
b l
c k
d )
2
= −g
−1 (η abcd ¯
m
a m
b l
c k
d )
2
= g
−1 V
2 ,
(2.30)
with the final equality coming from (2.22). Hence we have V 2 = 1 and so V = ±1.
From the definition (2.22) of V we see that a choice of sign for V corresponds to a
choice of orientation of the tetrad k a , l a , m a , ¯
m a . We shall choose V = −1. Hence
the three complex bivectors (2.26) satisfy the conditions
∗ L ab = −i L ab ,
∗ M ab = −i M ab and
∗ N ab = −i N ab ,
(2.31)
and any complex bivector F ab satisfying (2.6) can be written
F ab = f 1 L ab + f 2 M ab + f 3 N ab ,
(2.32)
for some complex scalars f 1 , f 2 , f 3 .
The following list of scalar products involving the bivector basis is useful:
L ab L
bc
= 0 , L ab M
bc
= −m a ¯
m
c
+ k a l
c , L ab N
bc
= −L a
c ,
M ab M
bc
= 0 , M ab N
bc
= M a
c , N ab N
bc
= δ
c
a ,
(2.33)
Hence in particular we have
L ab L
ab
= 0 , L ab M
ab
= −2 , L ab N
ab
= 0 ,
M ab M
ab
= 0 , M ab N
ab
= 0 , N ab N
ab
= −4 .
(2.34)
It thus follows from (2.32) that
F ab F
ab
= −4 f 1 f 2 − 4 f
2
3 .
(2.35)