

2.2 Image Feature Matching Experiment of RFID System Physical Anti-Collision
53
2.2.4 Algorithm Comparison Results and Analysis
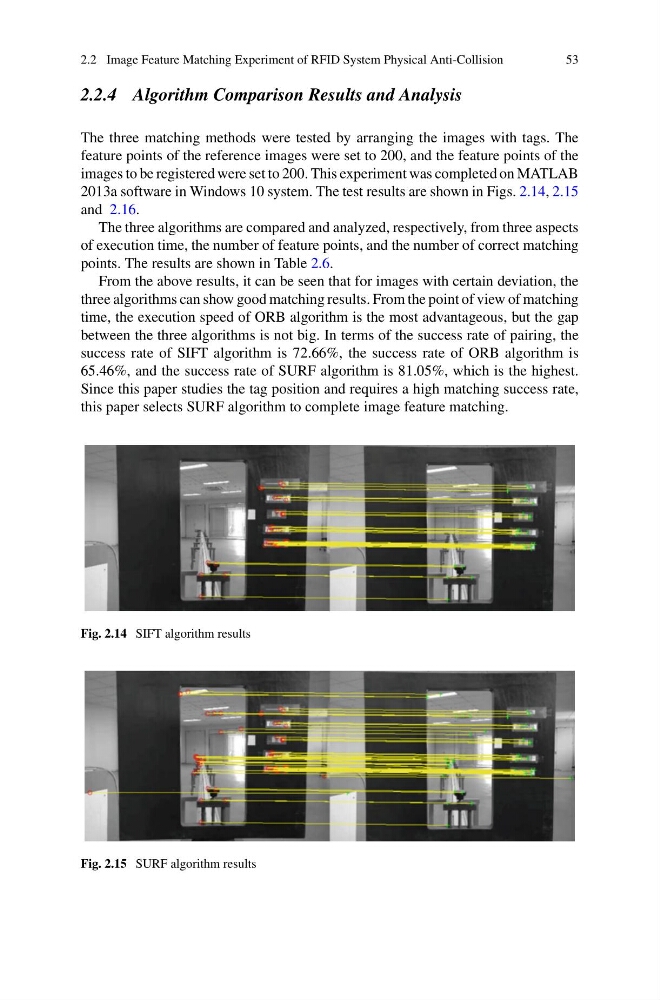
The three matching methods were tested by arranging the images with tags. The
feature points of the reference images were set to 200, and the feature points of the
images to be registered were set to 200. This experiment was completed on MATLAB
2013a software in Windows 10 system. The test results are shown in Figs. 2.14, 2.15
and 2.16.
The three algorithms are compared and analyzed, respectively, from three aspects
of execution time, the number of feature points, and the number of correct matching
points. The results are shown in Table 2.6.
From the above results, it can be seen that for images with certain deviation, the
three algorithms can show good matching results. From the point of view of matching
time, the execution speed of ORB algorithm is the most advantageous, but the gap
between the three algorithms is not big. In terms of the success rate of pairing, the
success rate of SIFT algorithm is 72.66%, the success rate of ORB algorithm is
65.46%, and the success rate of SURF algorithm is 81.05%, which is the highest.
Since this paper studies the tag position and requires a high matching success rate,
this paper selects SURF algorithm to complete image feature matching.
Fig. 2.14 SIFT algorithm results
Fig. 2.15 SURF algorithm results