

54
2 RFID System Physical Anti-Collision Experimental Verification
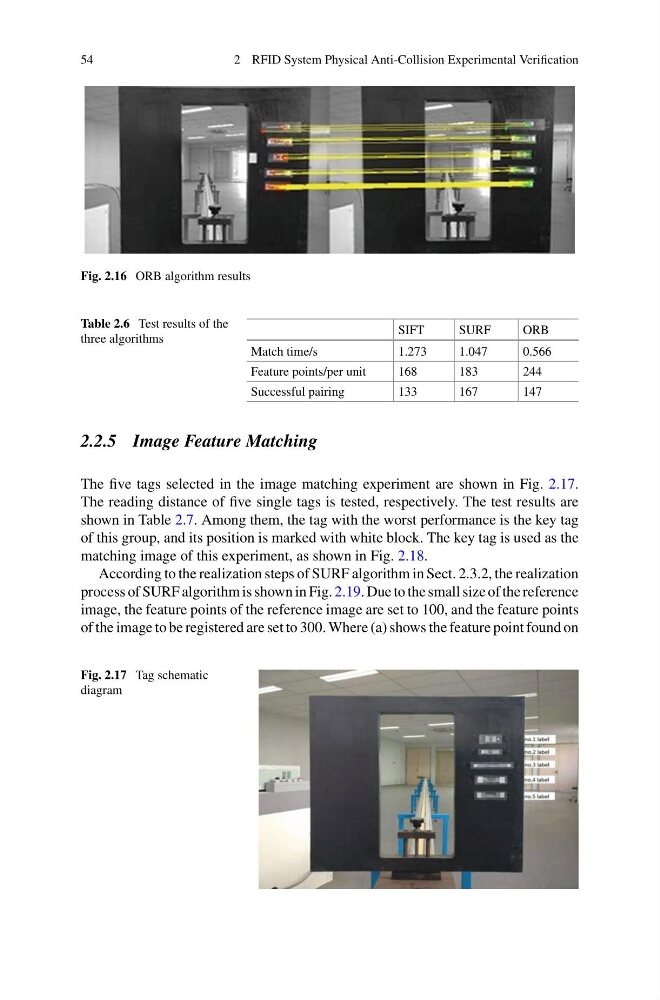
Fig. 2.16 ORB algorithm results
Table 2.6 Test results of the
three algorithms
SIFT
SURF
ORB
Match time/s
1.273
1.047
0.566
Feature points/per unit
168
183
244
Successful pairing
133
167
147
2.2.5 Image Feature Matching
The five tags selected in the image matching experiment are shown in Fig. 2.17.
The reading distance of five single tags is tested, respectively. The test results are
shown in Table 2.7. Among them, the tag with the worst performance is the key tag
of this group, and its position is marked with white block. The key tag is used as the
matching image of this experiment, as shown in Fig. 2.18.
According to the realization steps of SURF algorithm in Sect. 2.3.2, the realization
process of SURF algorithm is shown in Fig. 2.19. Due to the small size of the reference
image, the feature points of the reference image are set to 100, and the feature points
of the image to be registered are set to 300. Where (a) shows the feature point found on
Fig. 2.17 Tag schematic
diagram