

234
6 Deep Learning and RFID System Physical Anti-Collision
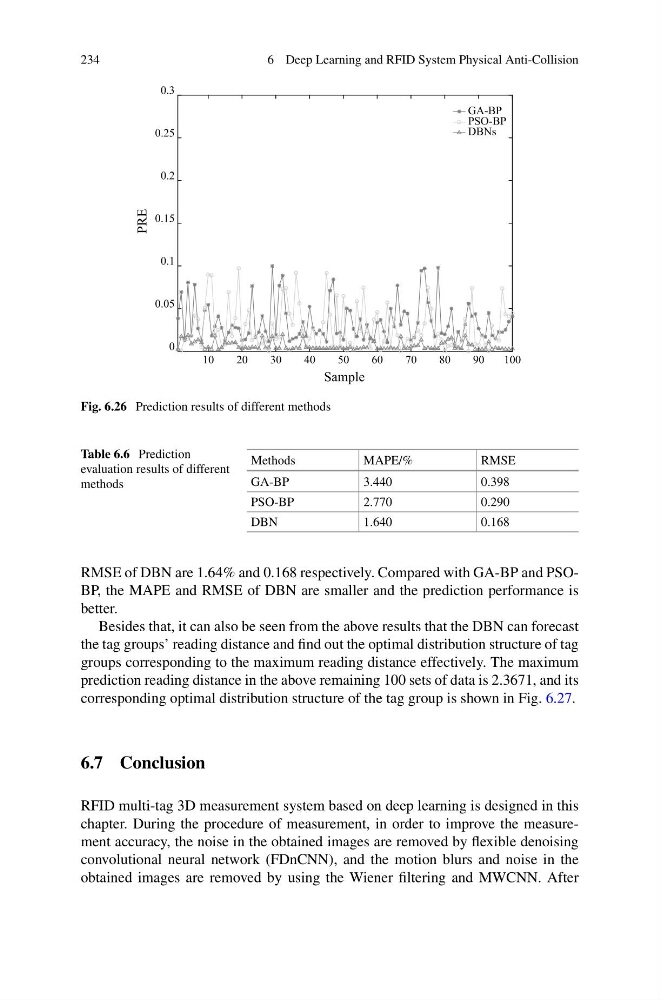
Fig. 6.26 Prediction results of different methods
Table 6.6 Prediction
evaluation results of different
methods
Methods
MAPE/%
RMSE
GA-BP
3.440
0.398
PSO-BP
2.770
0.290
DBN
1.640
0.168
RMSE of DBN are 1.64% and 0.168 respectively. Compared with GA-BP and PSOBP, the MAPE and RMSE of DBN are smaller and the prediction performance is
better.
Besides that, it can also be seen from the above results that the DBN can forecast
the tag groups’ reading distance and find out the optimal distribution structure of tag
groups corresponding to the maximum reading distance effectively. The maximum
prediction reading distance in the above remaining 100 sets of data is 2.3671, and its
corresponding optimal distribution structure of the tag group is shown in Fig. 6.27.
6.7 Conclusion
RFID multi-tag 3D measurement system based on deep learning is designed in this
chapter. During the procedure of measurement, in order to improve the measurement accuracy, the noise in the obtained images are removed by flexible denoising
convolutional neural network (FDnCNN), and the motion blurs and noise in the
obtained images are removed by using the Wiener filtering and MWCNN. After