

220
6 Deep Learning and RFID System Physical Anti-Collision
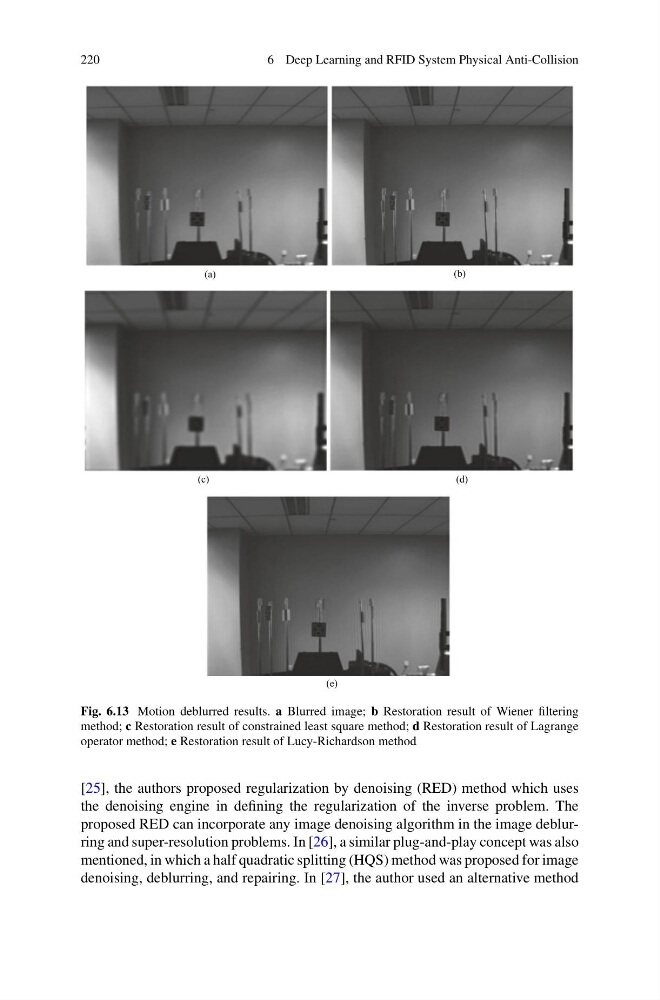
Fig. 6.13 Motion deblurred results. a Blurred image; b Restoration result of Wiener filtering
method; c Restoration result of constrained least square method; d Restoration result of Lagrange
operator method; e Restoration result of Lucy-Richardson method
[25], the authors proposed regularization by denoising (RED) method which uses
the denoising engine in defining the regularization of the inverse problem. The
proposed RED can incorporate any image denoising algorithm in the image deblurring and super-resolution problems. In [26], a similar plug-and-play concept was also
mentioned, in which a half quadratic splitting (HQS) method was proposed for image
denoising, deblurring, and repairing. In [27], the author used an alternative method