

218
6 Deep Learning and RFID System Physical Anti-Collision
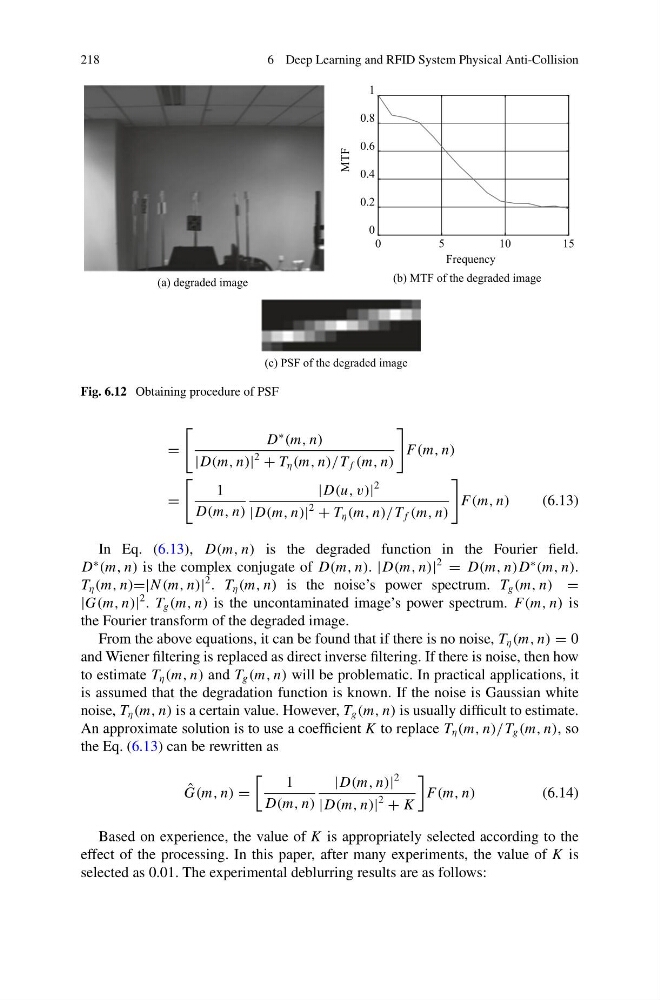
Fig. 6.12 Obtaining procedure of PSF
=
D
∗
(m, n)
|D(m, n)|
2
+ T η (m, n)/T f (m, n)
F(m, n)
=
1
D(m, n)
|D(u, v)|
2
|D(m, n)|
2
+ T η (m, n)/T f (m, n)
F(m, n)
(6.13)
In Eq. (6.13), D(m, n) is the degraded function in the Fourier field.
D
∗
(m, n) is the complex conjugate of D(m, n). |D(m, n)|
2
= D(m, n)D
∗
(m, n).
T η (m, n)=|N (m, n)|
2 . T η (m, n) is the noise’s power spectrum. T g (m, n) =
|G(m, n)|
2 . T g (m, n) is the uncontaminated image’s power spectrum. F(m, n) is
the Fourier transform of the degraded image.
From the above equations, it can be found that if there is no noise, T η (m, n) = 0
and Wiener filtering is replaced as direct inverse filtering. If there is noise, then how
to estimate T η (m, n) and T g (m, n) will be problematic. In practical applications, it
is assumed that the degradation function is known. If the noise is Gaussian white
noise, T η (m, n) is a certain value. However, T g (m, n) is usually difficult to estimate.
An approximate solution is to use a coefficient K to replace T η (m, n)/T g (m, n), so
the Eq. (6.13) can be rewritten as
ˆ
G(m, n) =
1
D(m, n)
|D(m, n)|
2
|D(m, n)|
2
+ K
F(m, n)
(6.14)
Based on experience, the value of K is appropriately selected according to the
effect of the processing. In this paper, after many experiments, the value of K is
selected as 0.01. The experimental deblurring results are as follows: