

140
4 Image Theory of RFID System Physical Anti-Collision
Table 4.6 Multi-tag three-dimensional spatial coordinate distribution
x 1 /m
y 1 /m
z 1 /m
…
x 7 /m
y 7 /m
z 7 /m
0.813
0.262
0.216
…
0.942
0.535
0.265
0.963
0.568
0.111
…
0.431
0.752
0.158
0.188
0.967
0.139
…
0.735
0.596
0.206
. . .
. . .
. . .
. . .
. . .
. . .
0.937
0.922
0.203
…
0.116
0.342
0.035
0.606
0.145
0.289
…
0.485
0.859
0.192
0.027
0.957
0.077
…
0.900
0.657
0.173
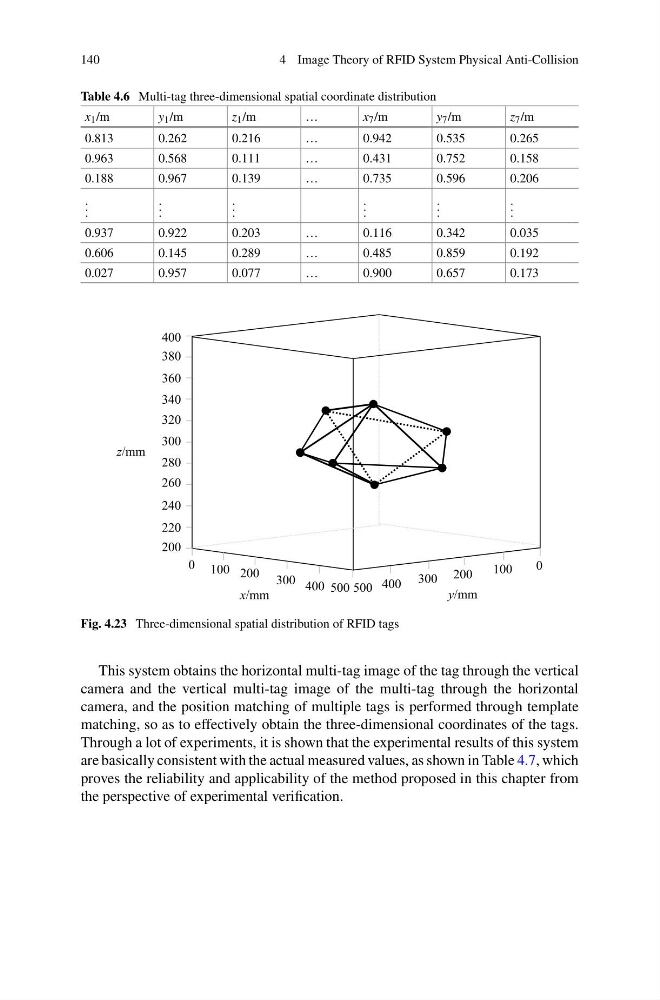
Fig. 4.23 Three-dimensional spatial distribution of RFID tags
This system obtains the horizontal multi-tag image of the tag through the vertical
camera and the vertical multi-tag image of the multi-tag through the horizontal
camera, and the position matching of multiple tags is performed through template
matching, so as to effectively obtain the three-dimensional coordinates of the tags.
Through a lot of experiments, it is shown that the experimental results of this system
are basically consistent with the actual measured values, as shown in Table 4.7, which
proves the reliability and applicability of the method proposed in this chapter from
the perspective of experimental verification.