

4.1 Tag Distribution Based on Image Matching
113
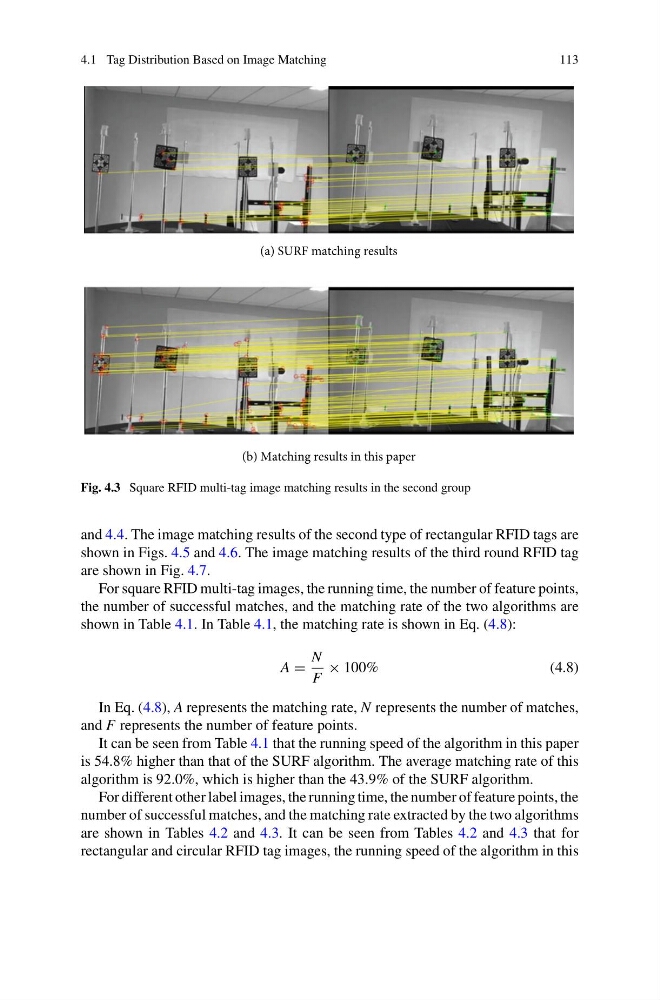
(a) SURF matching results
(b) Matching results in this paper
Fig. 4.3 Square RFID multi-tag image matching results in the second group
and 4.4. The image matching results of the second type of rectangular RFID tags are
shown in Figs. 4.5 and 4.6. The image matching results of the third round RFID tag
are shown in Fig. 4.7.
For square RFID multi-tag images, the running time, the number of feature points,
the number of successful matches, and the matching rate of the two algorithms are
shown in Table 4.1. In Table 4.1, the matching rate is shown in Eq. (4.8):
A =
N
F
× 100%
(4.8)
In Eq. (4.8), A represents the matching rate, N represents the number of matches,
and F represents the number of feature points.
It can be seen from Table 4.1 that the running speed of the algorithm in this paper
is 54.8% higher than that of the SURF algorithm. The average matching rate of this
algorithm is 92.0%, which is higher than the 43.9% of the SURF algorithm.
For different other label images, the running time, the number of feature points, the
number of successful matches, and the matching rate extracted by the two algorithms
are shown in Tables 4.2 and 4.3. It can be seen from Tables 4.2 and 4.3 that for
rectangular and circular RFID tag images, the running speed of the algorithm in this