

114
4 Image Theory of RFID System Physical Anti-Collision
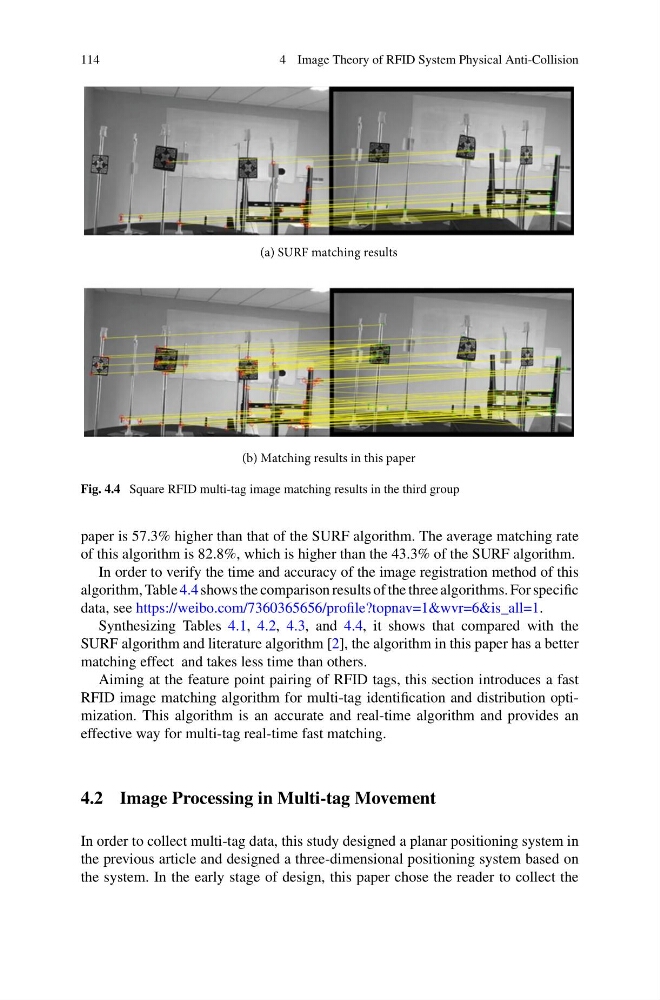
(a) SURF matching results
(b) Matching results in this paper
Fig. 4.4 Square RFID multi-tag image matching results in the third group
paper is 57.3% higher than that of the SURF algorithm. The average matching rate
of this algorithm is 82.8%, which is higher than the 43.3% of the SURF algorithm.
In order to verify the time and accuracy of the image registration method of this
algorithm, Table 4.4 shows the comparison results of the three algorithms. For specific
data, see https://weibo.com/7360365656/profile?topnav=1&wvr=6&is_all=1.
Synthesizing Tables 4.1, 4.2, 4.3, and 4.4, it shows that compared with the
SURF algorithm and literature algorithm [2], the algorithm in this paper has a better
matching effect and takes less time than others.
Aiming at the feature point pairing of RFID tags, this section introduces a fast
RFID image matching algorithm for multi-tag identification and distribution optimization. This algorithm is an accurate and real-time algorithm and provides an
effective way for multi-tag real-time fast matching.
4.2 Image Processing in Multi-tag Movement
In order to collect multi-tag data, this study designed a planar positioning system in
the previous article and designed a three-dimensional positioning system based on
the system. In the early stage of design, this paper chose the reader to collect the