

112
4 Image Theory of RFID System Physical Anti-Collision
within the block, and the vectors corresponding to all blocks are arranged in spatial
order to form the final feature descriptor.
Finally, when establishing a match, the algorithm determines the matching degree
by calculating the Euclidean distance between two feature points. The shorter the
distance, the better the match.
4.1.2 Experiment
In order to verify the accuracy of the improved algorithm, the simulation experiment
was implemented on a computer with an Intel(R) Core(TM) i5-9300H CPU2.4 GHz,
Window 10 operating system, and MATLABR2018a environment. First, the images
of this experiment are collected in the RFID dynamic test system [1]. The system
is mainly composed of reader antenna, laser rangefinder, CCD camera, drive motor,
RFID reader, reflector, guide rail, optical lifting platform, data display, and computer.
This experiment analyzes and compares the algorithm in this paper with the SURF
algorithm in terms of operating speed and matching accuracy. In order to verify the
robustness of the algorithm in this paper, the images selected in the experiment are
square RFID multi-tag image, rectangular RFID tag image, and circular RFID tag
image.
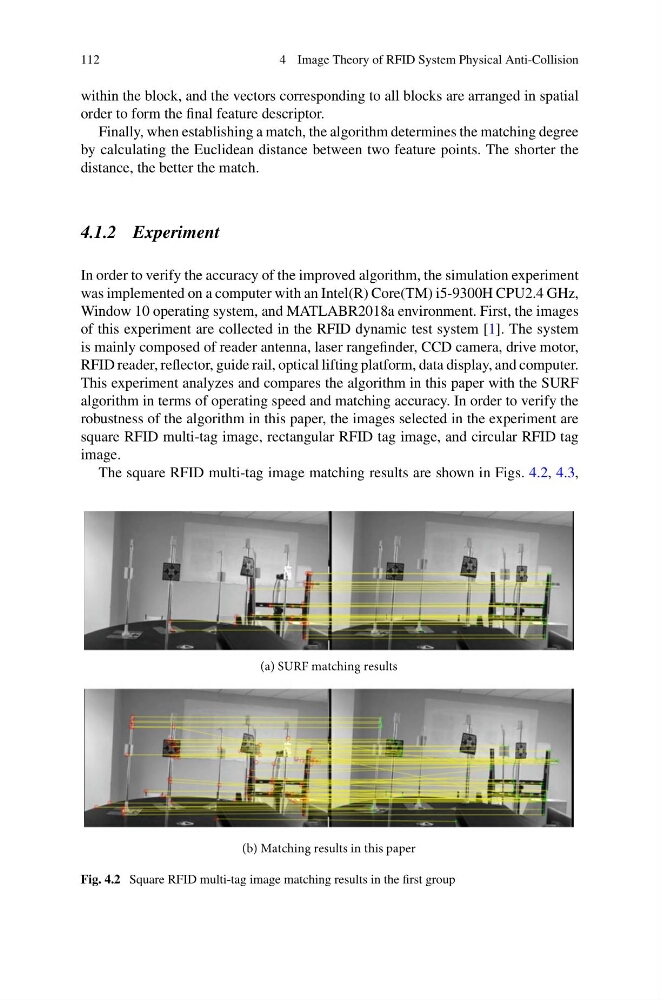
The square RFID multi-tag image matching results are shown in Figs. 4.2, 4.3,
(a) SURF matching results
(b) Matching results in this paper
Fig. 4.2 Square RFID multi-tag image matching results in the first group