

18
D. B. Marghitu and D. Cojocaru
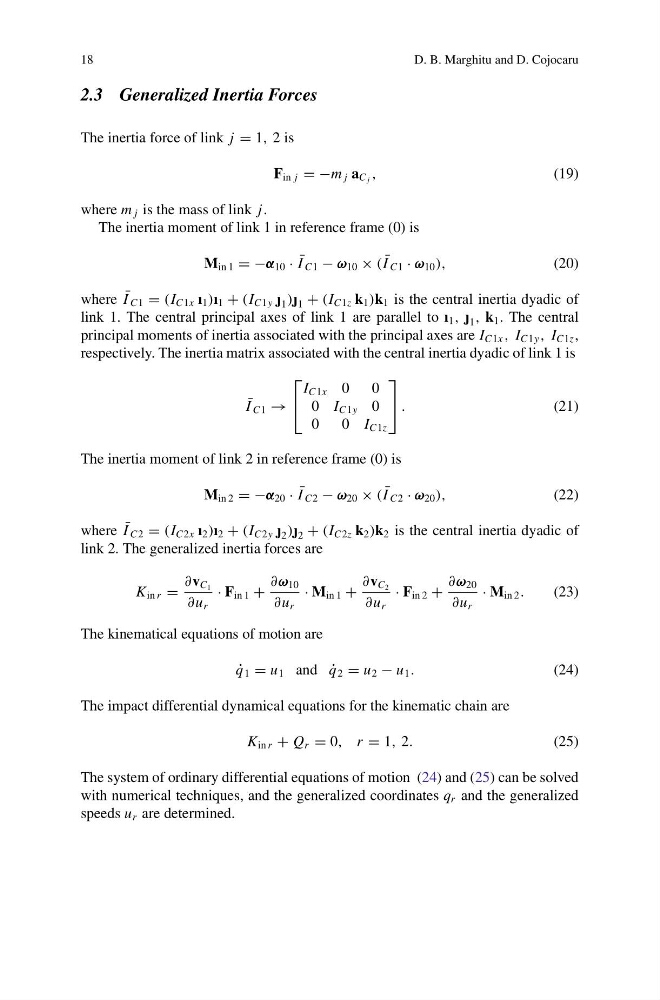
2.3 Generalized Inertia Forces
The inertia force of link j = 1, 2 is
F in j = −m j a C j ,
(19)
where m j is the mass of link j.
The inertia moment of link 1 in reference frame (0) is
M in 1 = −α 10 · ¯
I C1 − ω 10 × ( ¯
I C1 · ω 10 ),
(20)
where ¯
I C1 = (I C1x ı 1 )ı 1 + (I C1y j 1 )j 1 + (I C1z k 1 )k 1 is the central inertia dyadic of
link 1. The central principal axes of link 1 are parallel to ı 1 , j 1 , k 1 . The central
principal moments of inertia associated with the principal axes are I C1x , I C1y , I C1z ,
respectively. The inertia matrix associated with the central inertia dyadic of link 1 is
¯
I C1 →
⎡
⎣
I C1x 0 0
0 I C1y 0
0
0 I C1z
⎤
⎦ .
(21)
The inertia moment of link 2 in reference frame (0) is
M in 2 = −α 20 · ¯
I C2 − ω 20 × ( ¯
I C2 · ω 20 ),
(22)
where ¯
I C2 = (I C2x ı 2 )ı 2 + (I C2y j 2 )j 2 + (I C2z k 2 )k 2 is the central inertia dyadic of
link 2. The generalized inertia forces are
K in r =
∂v C 1
∂u r
· F in 1 +
∂ω 10
∂u r
· M in 1 +
∂v C 2
∂u r
· F in 2 +
∂ω 20
∂u r
· M in 2 .
(23)
The kinematical equations of motion are
˙
q 1 = u 1 and ˙
q 2 = u 2 − u 1 .
(24)
The impact differential dynamical equations for the kinematic chain are
K in r + Q r = 0, r = 1, 2.
(25)
The system of ordinary differential equations of motion (24) and (25) can be solved
with numerical techniques, and the generalized coordinates q r and the generalized
speeds u r are determined.