

16
D. B. Marghitu and D. Cojocaru
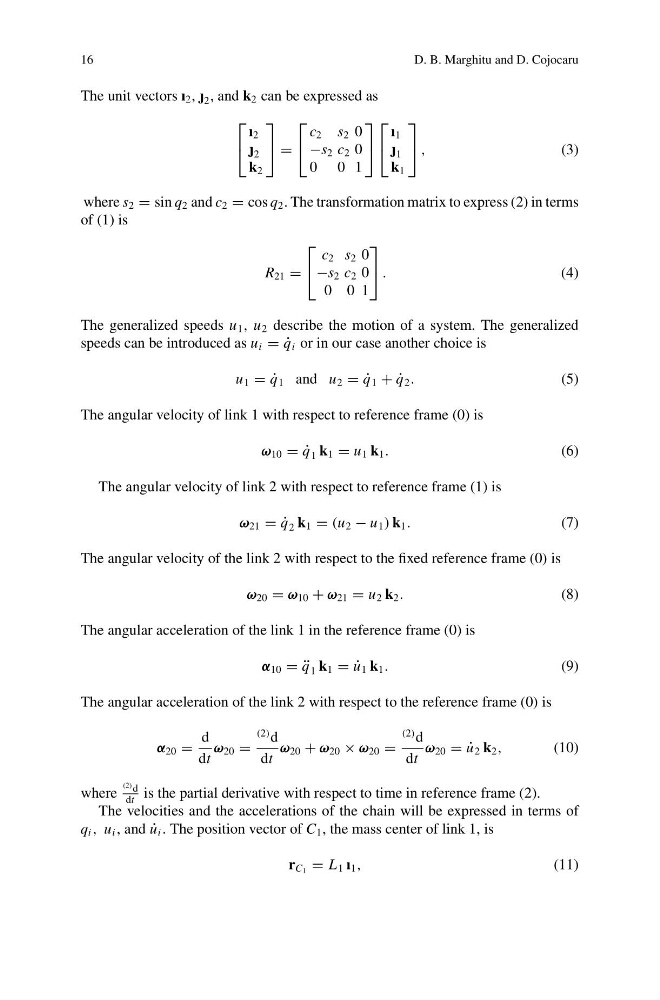
The unit vectors ı 2 , j 2 , and k 2 can be expressed as
⎡
⎣
ı 2
j 2
k 2
⎤
⎦ =
⎡
⎣
c 2 s 2 0
−s 2 c 2 0
0 0 1
⎤
⎦
⎡
⎣
ı 1
j 1
k 1
⎤
⎦ ,
(3)
where s 2 = sin q 2 and c 2 = cos q 2 . The transformation matrix to express (2) in terms
of (1) is
R 21 =
⎡
⎣
c 2 s 2 0
−s 2 c 2 0
0 0 1
⎤
⎦ .
(4)
The generalized speeds u 1 , u 2 describe the motion of a system. The generalized
speeds can be introduced as u i = ˙
q i or in our case another choice is
u 1 = ˙
q 1 and u 2 = ˙
q 1 + ˙
q 2 .
(5)
The angular velocity of link 1 with respect to reference frame (0) is
ω 10 = ˙
q 1 k 1 = u 1 k 1 .
(6)
The angular velocity of link 2 with respect to reference frame (1) is
ω 21 = ˙
q 2 k 1 = (u 2 − u 1 ) k 1 .
(7)
The angular velocity of the link 2 with respect to the fixed reference frame (0) is
ω 20 = ω 10 + ω 21 = u 2 k 2 .
(8)
The angular acceleration of the link 1 in the reference frame (0) is
α 10 = ¨
q 1 k 1 = ˙
u 1 k 1 .
(9)
The angular acceleration of the link 2 with respect to the reference frame (0) is
α 20 =
d
dt
ω 20 =
(2) d
dt
ω 20 + ω 20 × ω 20 =
(2) d
dt
ω 20 = ˙
u 2 k 2 ,
(10)
where
(2) d
dt
is the partial derivative with respect to time in reference frame (2).
The velocities and the accelerations of the chain will be expressed in terms of
q i , u i , and ˙
u i . The position vector of C 1 , the mass center of link 1, is
r C 1 = L 1 ı 1 ,
(11)