

Dynamics of the Impact with Benson Friction Model
15
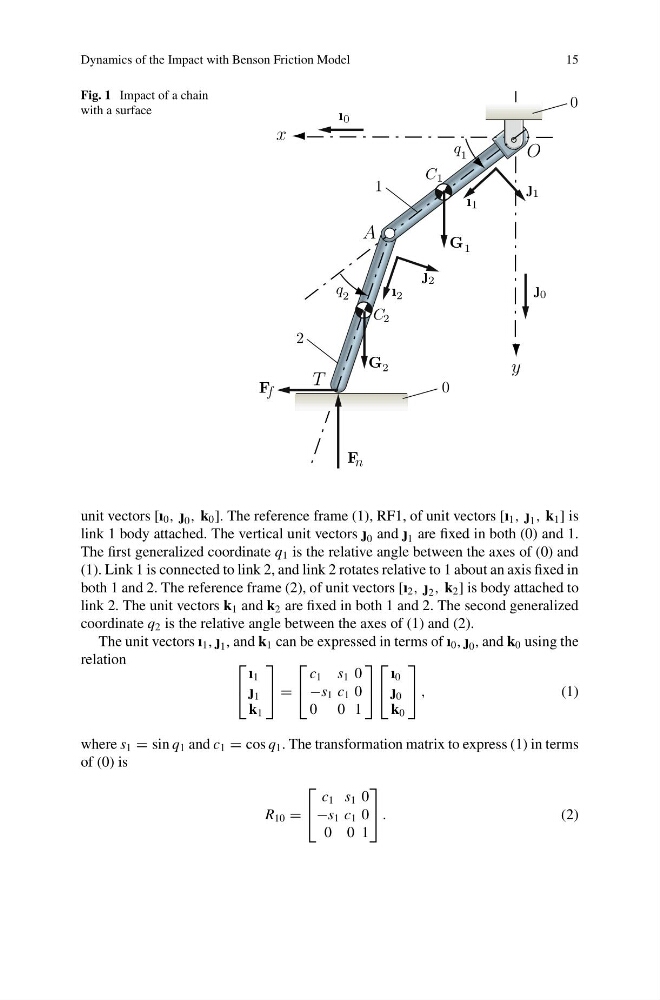
Fig. 1 Impact of a chain
with a surface
O
x
y
T
A
ı 0
ı 1
j 0
F
2
C
q 2
2
q 1
1
ı
1
C 2
n
F f
j 1
j 2
0
0
G
G
2
1
unit vectors [ı 0 , j 0 , k 0 ]. The reference frame (1), RF1, of unit vectors [ı 1 , j 1 , k 1 ] is
link 1 body attached. The vertical unit vectors j 0 and j 1 are fixed in both (0) and 1.
The first generalized coordinate q 1 is the relative angle between the axes of (0) and
(1). Link 1 is connected to link 2, and link 2 rotates relative to 1 about an axis fixed in
both 1 and 2. The reference frame (2), of unit vectors [ı 2 , j 2 , k 2 ] is body attached to
link 2. The unit vectors k 1 and k 2 are fixed in both 1 and 2. The second generalized
coordinate q 2 is the relative angle between the axes of (1) and (2).
The unit vectors ı 1 , j 1 , and k 1 can be expressed in terms of ı 0 , j 0 , and k 0 using the
relation
⎡
⎣
ı 1
j 1
k 1
⎤
⎦ =
⎡
⎣
c 1 s 1 0
−s 1 c 1 0
0 0 1
⎤
⎦
⎡
⎣
ı 0
j 0
k 0
⎤
⎦ ,
(1)
where s 1 = sin q 1 and c 1 = cos q 1 . The transformation matrix to express (1) in terms
of (0) is
R 10 =
⎡
⎣
c 1 s 1 0
−s 1 c 1 0
0 0 1
⎤
⎦ .
(2)