

308
D. Vl˘ adaia et al.
In the three relations, (3) were defined the force F 0 amplitude, the phase ϕ of the
deformation and the response force of the model, as well as the internal friction coefficient, δ. The (1) and (2) are the parametric equations for an ellipse. By eliminating
the time between two above equations, a family of ellipses was obtained having δ or
ϕ as a parameter.
F
F 0
2
+
X
X 0
2
− 2
F
F 0
X
X 0
cos ϕ = sin
2
ϕ.
(4)
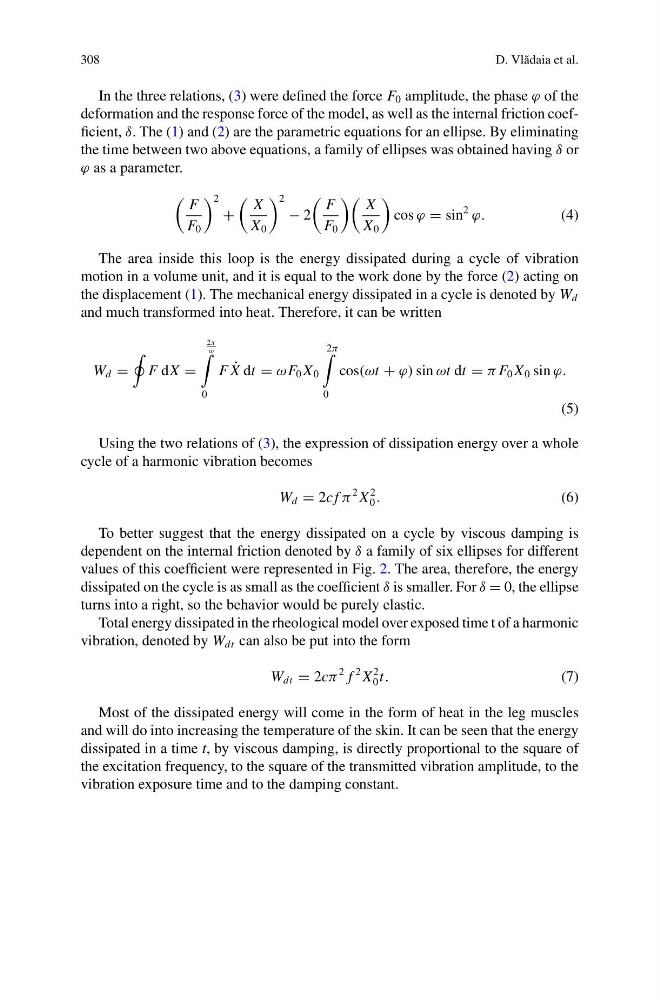
The area inside this loop is the energy dissipated during a cycle of vibration
motion in a volume unit, and it is equal to the work done by the force (2) acting on
the displacement (1). The mechanical energy dissipated in a cycle is denoted by W d
and much transformed into heat. Therefore, it can be written
W d =
F dX =
2π
ω
0
F ˙
X dt = ωF 0 X 0
2π
0
cos(ωt + ϕ) sin ωt dt = π F 0 X 0 sin ϕ.
(5)
Using the two relations of (3), the expression of dissipation energy over a whole
cycle of a harmonic vibration becomes
W d = 2c f π
2 X
2
0 .
(6)
To better suggest that the energy dissipated on a cycle by viscous damping is
dependent on the internal friction denoted by δ a family of six ellipses for different
values of this coefficient were represented in Fig. 2. The area, therefore, the energy
dissipated on the cycle is as small as the coefficient δ is smaller. For δ = 0, the ellipse
turns into a right, so the behavior would be purely elastic.
Total energy dissipated in the rheological model over exposed time t of a harmonic
vibration, denoted by W dt can also be put into the form
W dt = 2cπ
2 f
2 X
2
0 t.
(7)
Most of the dissipated energy will come in the form of heat in the leg muscles
and will do into increasing the temperature of the skin. It can be seen that the energy
dissipated in a time t, by viscous damping, is directly proportional to the square of
the excitation frequency, to the square of the transmitted vibration amplitude, to the
vibration exposure time and to the damping constant.