

Modelling of Frictional Contacts in 3D Dynamics …
11
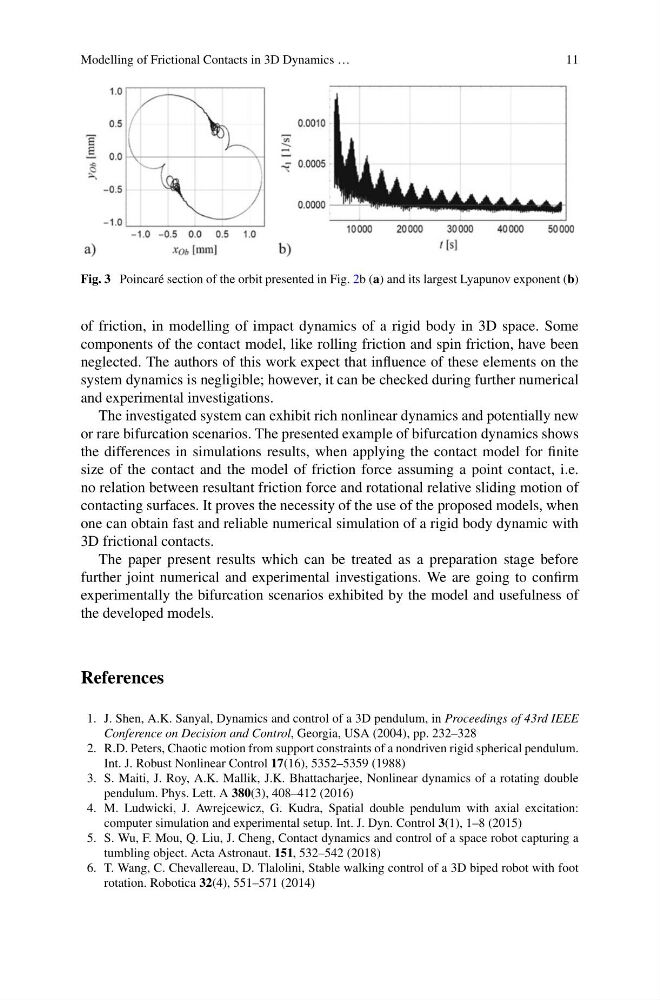
Fig. 3 Poincaré section of the orbit presented in Fig. 2b (a) and its largest Lyapunov exponent (b)
of friction, in modelling of impact dynamics of a rigid body in 3D space. Some
components of the contact model, like rolling friction and spin friction, have been
neglected. The authors of this work expect that influence of these elements on the
system dynamics is negligible; however, it can be checked during further numerical
and experimental investigations.
The investigated system can exhibit rich nonlinear dynamics and potentially new
or rare bifurcation scenarios. The presented example of bifurcation dynamics shows
the differences in simulations results, when applying the contact model for finite
size of the contact and the model of friction force assuming a point contact, i.e.
no relation between resultant friction force and rotational relative sliding motion of
contacting surfaces. It proves the necessity of the use of the proposed models, when
one can obtain fast and reliable numerical simulation of a rigid body dynamic with
3D frictional contacts.
The paper present results which can be treated as a preparation stage before
further joint numerical and experimental investigations. We are going to confirm
experimentally the bifurcation scenarios exhibited by the model and usefulness of
the developed models.
References
1. J. Shen, A.K. Sanyal, Dynamics and control of a 3D pendulum, in Proceedings of 43rd IEEE
Conference on Decision and Control, Georgia, USA (2004), pp. 232–328
2. R.D. Peters, Chaotic motion from support constraints of a nondriven rigid spherical pendulum.
Int. J. Robust Nonlinear Control 17(16), 5352–5359 (1988)
3. S. Maiti, J. Roy, A.K. Mallik, J.K. Bhattacharjee, Nonlinear dynamics of a rotating double
pendulum. Phys. Lett. A 380(3), 408–412 (2016)
4. M. Ludwicki, J. Awrejcewicz, G. Kudra, Spatial double pendulum with axial excitation:
computer simulation and experimental setup. Int. J. Dyn. Control 3(1), 1–8 (2015)
5. S. Wu, F. Mou, Q. Liu, J. Cheng, Contact dynamics and control of a space robot capturing a
tumbling object. Acta Astronaut. 151, 532–542 (2018)
6. T. Wang, C. Chevallereau, D. Tlalolini, Stable walking control of a 3D biped robot with foot
rotation. Robotica 32(4), 551–571 (2014)