

Modelling of Frictional Contacts in 3D Dynamics …
9
where ν 1 and ν 2 are Poisson’s coefficients of materials of the contacting bodies, while
E 1 and E 2 are their Young’s modulus.
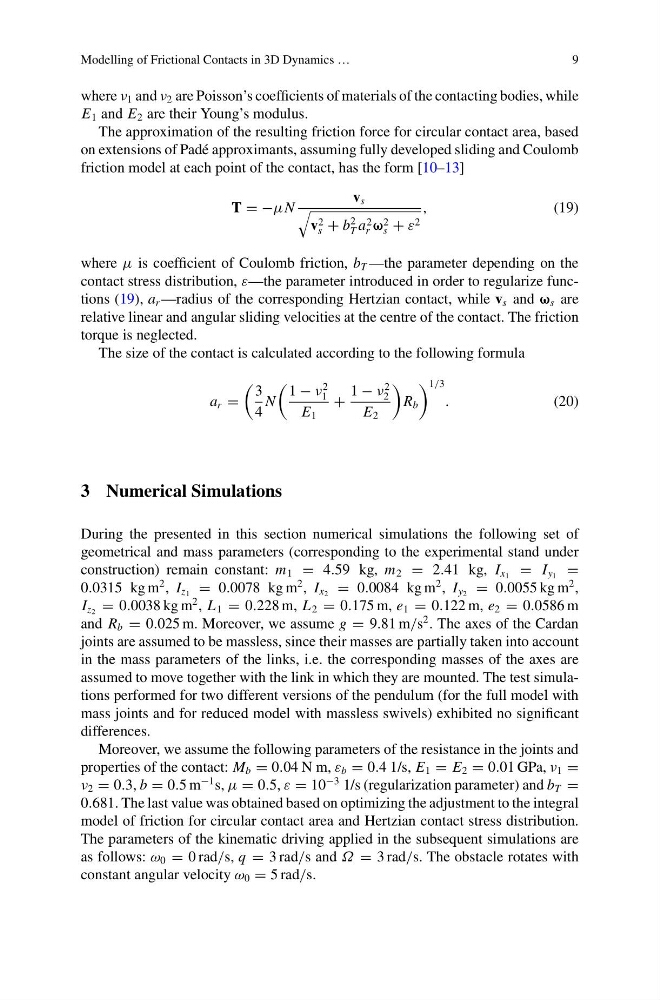
The approximation of the resulting friction force for circular contact area, based
on extensions of Padé approximants, assuming fully developed sliding and Coulomb
friction model at each point of the contact, has the form [10–13]
T = −μN
v s
v 2
s + b
2
T a 2
r ω 2
s + ε 2
,
(19)
where μ is coefficient of Coulomb friction, b T —the parameter depending on the
contact stress distribution, ε—the parameter introduced in order to regularize functions (19), a r —radius of the corresponding Hertzian contact, while v s and ω s are
relative linear and angular sliding velocities at the centre of the contact. The friction
torque is neglected.
The size of the contact is calculated according to the following formula
a r =
3
4
N
1 − ν
2
1
E 1
+
1 − ν
2
2
E 2
R b
1/3
.
(20)
3 Numerical Simulations
During the presented in this section numerical simulations the following set of
geometrical and mass parameters (corresponding to the experimental stand under
construction) remain constant: m 1 = 4.59 kg, m 2 = 2.41 kg, I x 1 = I y 1 =
0.0315 kg m
2 , I z 1 = 0.0078 kg m
2 , I x 2 = 0.0084 kg m
2 , I y 2 = 0.0055 kg m
2 ,
I z 2 = 0.0038 kg m
2 , L 1 = 0.228 m, L 2 = 0.175 m, e 1 = 0.122 m, e 2 = 0.0586 m
and R b = 0.025 m. Moreover, we assume g = 9.81 m/s
2 . The axes of the Cardan
joints are assumed to be massless, since their masses are partially taken into account
in the mass parameters of the links, i.e. the corresponding masses of the axes are
assumed to move together with the link in which they are mounted. The test simulations performed for two different versions of the pendulum (for the full model with
mass joints and for reduced model with massless swivels) exhibited no significant
differences.
Moreover, we assume the following parameters of the resistance in the joints and
properties of the contact: M b = 0.04 N m, ε b = 0.4 1/s, E 1 = E 2 = 0.01 GPa, ν 1 =
ν 2 = 0.3, b = 0.5 m
−1 s, μ = 0.5, ε = 10
−3 1/s (regularization parameter) and b T =
0.681. The last value was obtained based on optimizing the adjustment to the integral
model of friction for circular contact area and Hertzian contact stress distribution.
The parameters of the kinematic driving applied in the subsequent simulations are
as follows: ω 0 = 0 rad/s, q = 3 rad/s and Ω = 3 rad/s. The obstacle rotates with
constant angular velocity ω 0 = 5 rad/s.