

Fundamental concepts 19
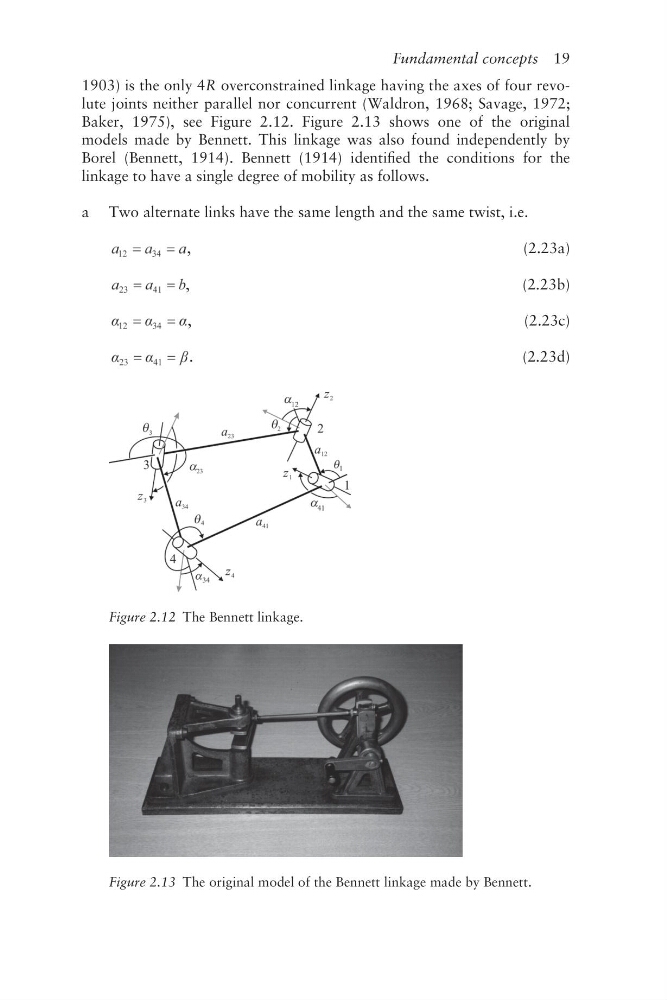
1903) is the only 4R overconstrained linkage having the axes of four revolute joints neither parallel nor concurrent (Waldron, 1968; Savage, 1972;
Baker, 1975), see Figure 2.12. Figure 2.13 shows one of the original
models made by Bennett. This linkage was also found independently by
Borel (Bennett, 1914). Bennett (1914) identified the conditions for the
linkage to have a single degree of mobility as follows.
a Two alternate links have the same length and the same twist, i.e.
,
(2.23a)
,
(2.23b)
,
(2.23c)
.
(2.23d)
Figure 2.12 The Bennett linkage.
Figure 2.13 The original model of the Bennett linkage made by Bennett.