

16 Fundamental concepts
twists and offsets are zero. The homogeneous coordinates can then be
replaced by three dimensional vectors
,
(2.18)
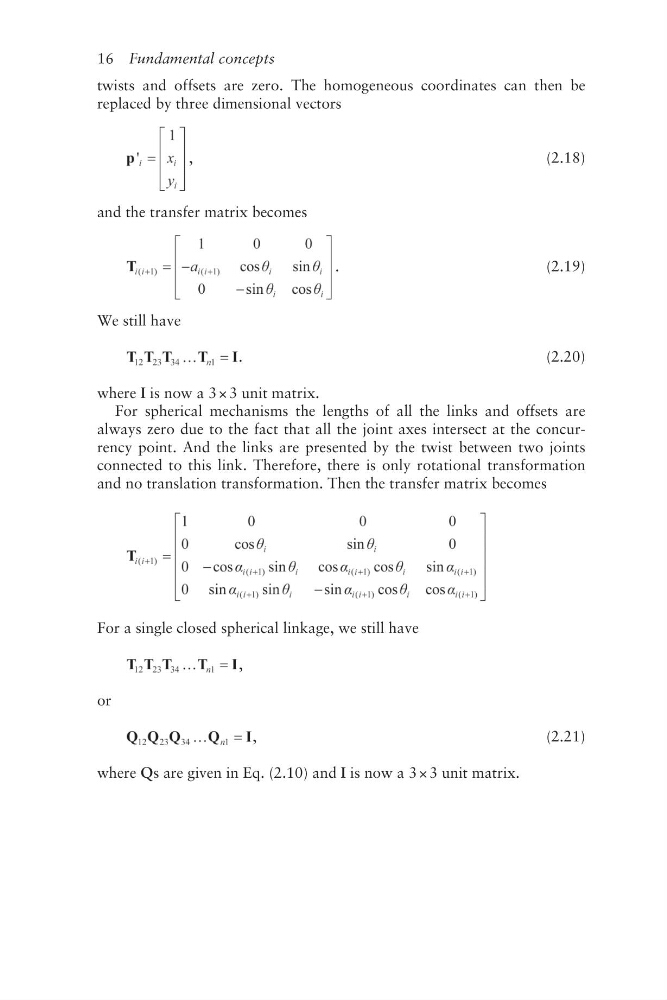
and the transfer matrix becomes
.
(2.19)
We still have
.
(2.20)
where I is now a 3 × 3 unit matrix.
For spherical mechanisms the lengths of all the links and offsets are
always zero due to the fact that all the joint axes intersect at the concurrency point. And the links are presented by the twist between two joints
connected to this link. Therefore, there is only rotational transformation
and no translation transformation. Then the transfer matrix becomes
For a single closed spherical linkage, we still have
,
or
,
(2.21)
where Qs are given in Eq. (2.10) and I is now a 3 × 3 unit matrix.