

14 Fundamental concepts
follows. The length of link(i – 1)i, a (i–1)i , is the shortest distance between
axes z i–1 and z i ; the twist of link (i – 1)i, a (i–1)i , is the angle of rotation from
axes z i–1 to z i positively about axis x i ; and the offset of joint i, R i , is the distance from link (i – 1)i to link i(i + 1) positively about z i . The kinematic
parameter of the revolution of joints, the revolute variable of the linkage,
θ i , is the angle of rotation from x i–1 to x i positively about z i . Therefore, the
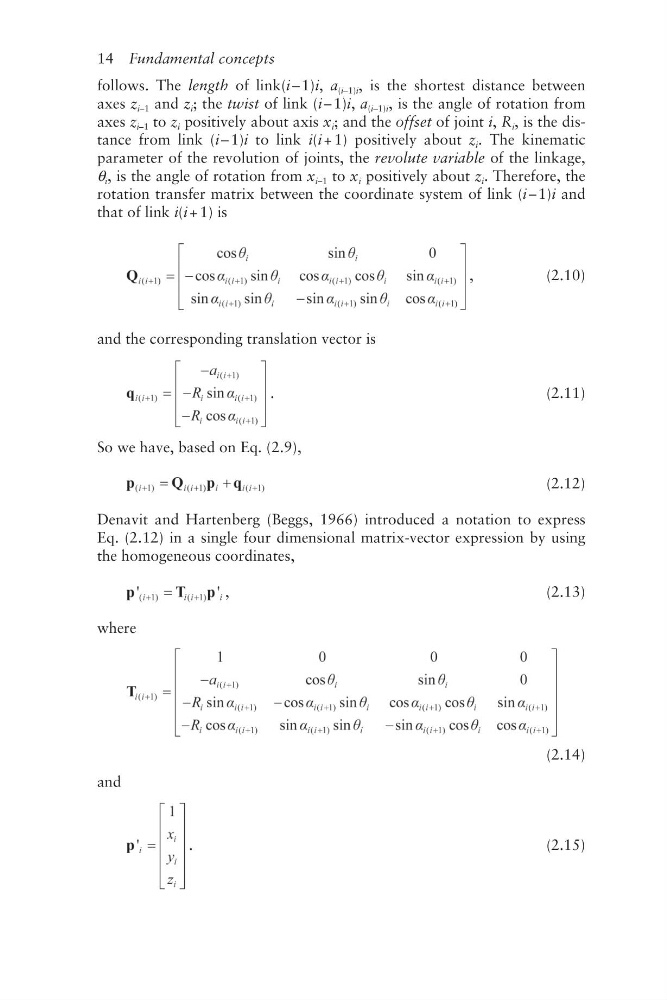
rotation transfer matrix between the coordinate system of link (i – 1)i and
that of link i(i + 1) is
,
(2.10)
and the corresponding translation vector is
.
(2.11)
So we have, based on Eq. (2.9),
(2.12)
Denavit and Hartenberg (Beggs, 1966) introduced a notation to express
Eq. (2.12) in a single four dimensional matrix- vector expression by using
the homogeneous coordinates,
,
(2.13)
where
(2.14)
and
.
(2.15)