

Fundamental concepts 13
reference frame, and q 12 is the vector related to the translation of the origin
of the moving reference frame relative to the fixed reference frame.
We can apply this transformation model to a serial chain by establishing
a convention that defines a consistent location for the reference frame in
each member of the chain. The transformations representing the positions
of the joints can then be applied successfully to produce the transformation
relating to the end members of the chain.
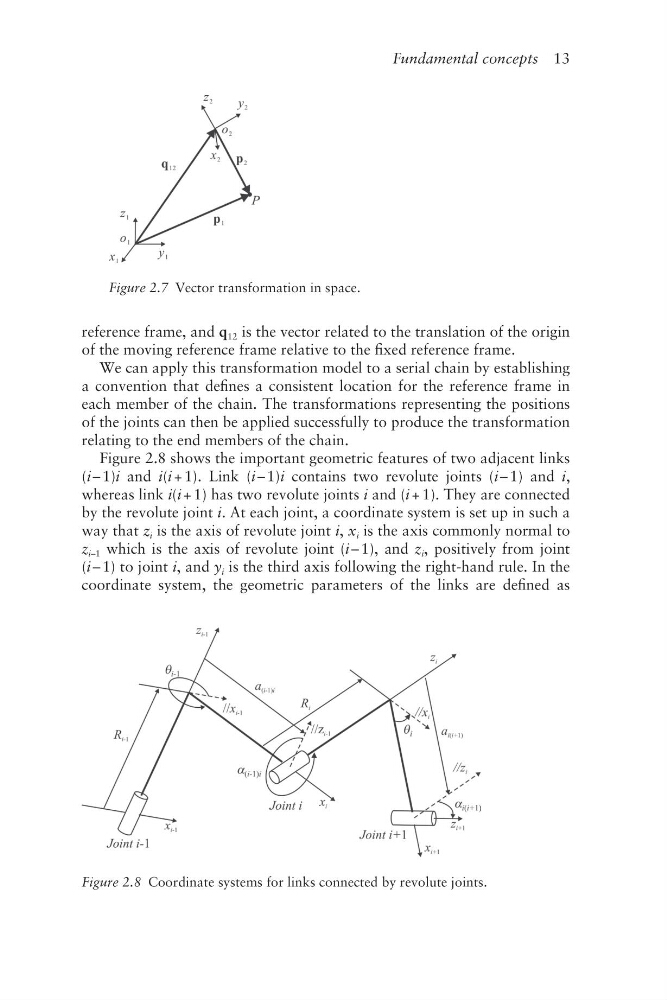
Figure 2.8 shows the important geometric features of two adjacent links
(i – 1)i and i(i + 1). Link (i – 1)i contains two revolute joints (i – 1) and i,
whereas link i(i + 1) has two revolute joints i and (i + 1). They are connected
by the revolute joint i. At each joint, a coordinate system is set up in such a
way that z i is the axis of revolute joint i, x i is the axis commonly normal to
z i–1 which is the axis of revolute joint (i – 1), and z i , positively from joint
(i – 1) to joint i, and y i is the third axis following the right- hand rule. In the
coordinate system, the geometric parameters of the links are defined as
Figure 2.7 Vector transformation in space.
Figure 2.8 Coordinate systems for links connected by revolute joints.