

70
4 Multi-Degree of Freedom (MDOF) Systems
This condition is a homogeneous system of n linear algebraic equations for . Its
trivial solution = 0 is not acceptable for non-zero initial conditions since, if
= 0, then x(t) = 0 at all times, which would be at variance with non-zero
initial conditions. Our interest is in non-trivial solutions of this algebraic system of
equations.
4.3.1 Modal Frequencies and Shapes
We have shown that a homogeneous system of equations admits non-trivial solutions
if its determinant is zero. Accordingly, the homogeneous system in Eq. 4.4 admits
non-trivial solutions = 0 if the determinant of matrix
− m ω 2 + k
is zero. Since
this matrix depends on the unspecified parameter ω 2 , it is likely that the requirement
det
− m ω 2 + k
= 0 can be satisfied. It turns out that the values of ω 2 for which
det
−m ω 2 +k
= 0 have physical meaning and so do the corresponding non-trivial
solutions of Eq. 4.4.
The solution of the homogeneous system of algebraic equations in Eq. 4.4
involves the following two steps.
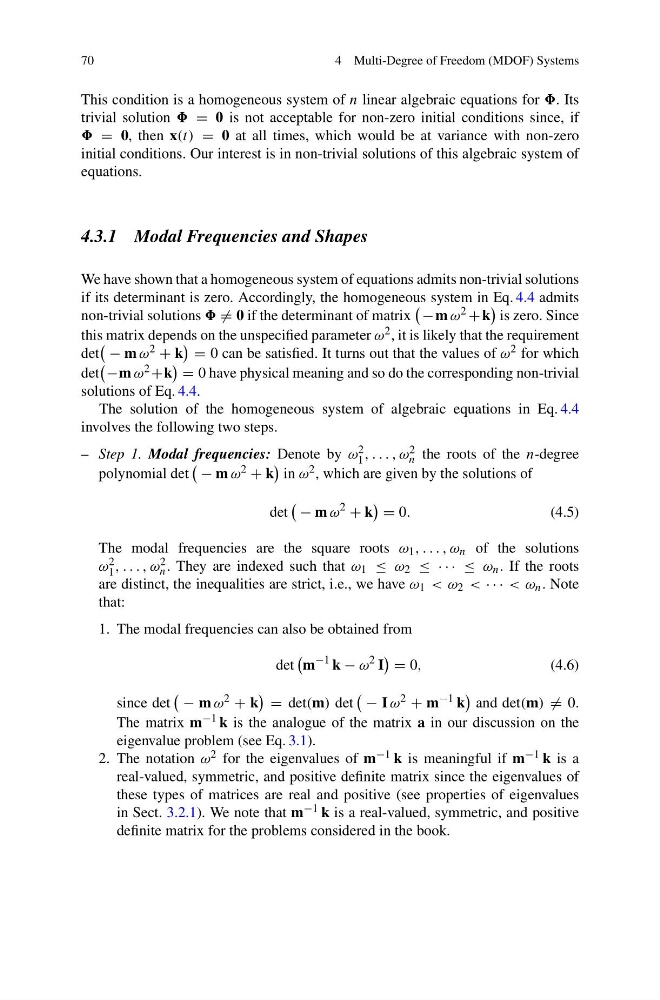
– Step 1. Modal frequencies: Denote by ω 2
1 , . . . , ω 2
n the roots of the n-degree
polynomial det
− m ω 2 + k
in ω 2 , which are given by the solutions of
det
− m ω
2
+ k
= 0.
(4.5)
The modal frequencies are the square roots ω 1 , . . . , ω n of the solutions
ω 2
1 , . . . , ω 2
n . They are indexed such that ω 1 ≤ ω 2 ≤ · · · ≤ ω n . If the roots
are distinct, the inequalities are strict, i.e., we have ω 1 < ω 2 < · · · < ω n . Note
that:
1. The modal frequencies can also be obtained from
det
m
−1 k − ω
2 I
= 0,
(4.6)
since det
− m ω 2 + k
= det(m) det
− I ω 2 + m −1 k
and det(m) = 0.
The matrix m −1 k is the analogue of the matrix a in our discussion on the
eigenvalue problem (see Eq. 3.1).
2. The notation ω 2 for the eigenvalues of m −1 k is meaningful if m −1 k is a
real-valued, symmetric, and positive definite matrix since the eigenvalues of
these types of matrices are real and positive (see properties of eigenvalues
in Sect. 3.2.1). We note that m −1 k is a real-valued, symmetric, and positive
definite matrix for the problems considered in the book.