

118
5 Continuous Systems
We proceed by using the following standard arguments when dealing with partial
differential equations, to clarify the notation ω 2 , a positive constant.
• The terms (E I /m)
ϕ I V /ϕ
and ¨
q/q are functions of only x and t, respectively.
They must be constant for the following reason. Suppose we fix x so that
(E I /m)
ϕ I V /ϕ
is a constant. Then, ¨
q/q must take the same value at all times,
which is equal to that of (E I /m)
ϕ I V /ϕ
for the selected x. A similar argument
shows that (E I /m)
ϕ I V /ϕ
does not change with x for an arbitrary fixed time
t. We denote the constant value of these terms by ω 2 .
• The constant value of (E I /m)
ϕ I V /ϕ
and − ¨
q/q must be strictly positive for
the following reason. Consider the differential equation of q(t) given by Eq. 5.5.
If the constant is strictly positive, then q(t) satisfies the equation ¨
q + ω 2 q = 0
whose solution is q(t) = A cos(ω t)+B sin(ω t). If we set the constant in Eq. 5.5
to be strictly negative, i.e., −ω 2 in place of ω 2 , then q(t) satisfies ¨
q − ω 2 q = 0
whose solution is q(t) = C 1 exp(ω t) + C 2 exp(−ω t). The latter solution is
physically unrealizable since it converges to ±∞ as t → ∞, although there is
no input (free vibration). In contrast, the solution corresponding to the positive
constant ω 2 is oscillatory in agreement with physics.
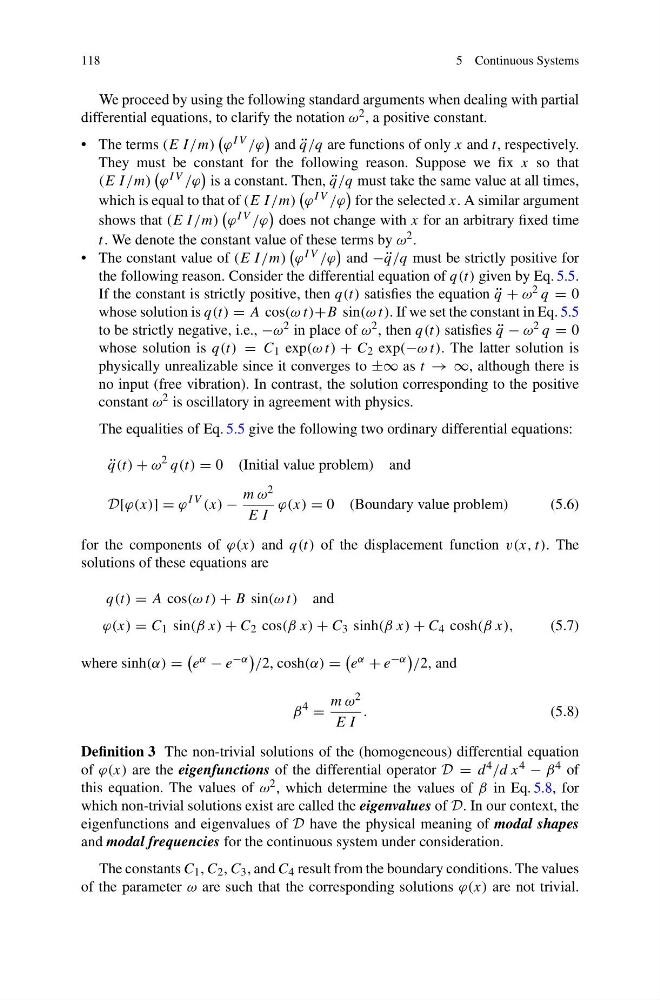
The equalities of Eq. 5.5 give the following two ordinary differential equations:
¨
q(t) + ω
2 q(t) = 0 (Initial value problem) and
D[ϕ(x)] = ϕ
I V (x) −
m ω 2
E I
ϕ(x) = 0 (Boundary value problem)
(5.6)
for the components of ϕ(x) and q(t) of the displacement function v(x, t). The
solutions of these equations are
q(t) = A cos(ω t) + B sin(ω t) and
ϕ(x) = C 1 sin(β x) + C 2 cos(β x) + C 3 sinh(β x) + C 4 cosh(β x),
(5.7)
where sinh(α) =
e α − e −α
/2, cosh(α) =
e α + e −α
/2, and
β
4
=
m ω 2
E I
.
(5.8)
Definition 3 The non-trivial solutions of the (homogeneous) differential equation
of ϕ(x) are the eigenfunctions of the differential operator D = d 4 /d x 4 − β 4 of
this equation. The values of ω 2 , which determine the values of β in Eq. 5.8, for
which non-trivial solutions exist are called the eigenvalues of D. In our context, the
eigenfunctions and eigenvalues of D have the physical meaning of modal shapes
and modal frequencies for the continuous system under consideration.
The constants C 1 , C 2 , C 3 , and C 4 result from the boundary conditions. The values
of the parameter ω are such that the corresponding solutions ϕ(x) are not trivial.