

94
4 Multi-Degree of Freedom (MDOF) Systems
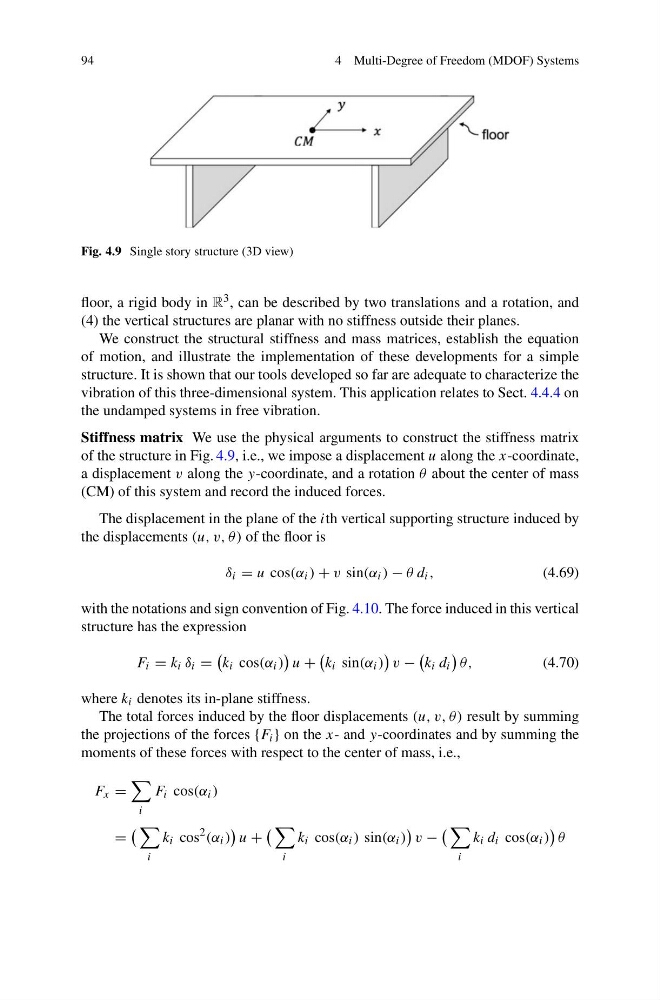
Fig. 4.9 Single story structure (3D view)
floor, a rigid body in R 3 , can be described by two translations and a rotation, and
(4) the vertical structures are planar with no stiffness outside their planes.
We construct the structural stiffness and mass matrices, establish the equation
of motion, and illustrate the implementation of these developments for a simple
structure. It is shown that our tools developed so far are adequate to characterize the
vibration of this three-dimensional system. This application relates to Sect. 4.4.4 on
the undamped systems in free vibration.
Stiffness matrix We use the physical arguments to construct the stiffness matrix
of the structure in Fig. 4.9, i.e., we impose a displacement u along the x-coordinate,
a displacement v along the y-coordinate, and a rotation θ about the center of mass
(CM) of this system and record the induced forces.
The displacement in the plane of the ith vertical supporting structure induced by
the displacements (u, v, θ) of the floor is
δ i = u cos(α i ) + v sin(α i ) − θ d i ,
(4.69)
with the notations and sign convention of Fig. 4.10. The force induced in this vertical
structure has the expression
F i = k i δ i =
k i cos(α i )
u +
k i sin(α i )
v −
k i d i
θ,
(4.70)
where k i denotes its in-plane stiffness.
The total forces induced by the floor displacements (u, v, θ) result by summing
the projections of the forces {F i } on the x- and y-coordinates and by summing the
moments of these forces with respect to the center of mass, i.e.,
F x =
i
F i cos(α i )
=
i
k i cos
2 (α i )
u +
i
k i cos(α i ) sin(α i )
v −
i
k i d i cos(α i )
θ