

4 Contact Hamiltonian Systems for Probability Distribution Functions …
73
Since p
eq
θ ( j) = 0 and
eq
(θ ) < ∞ by assumptions, the function exists. Generalizing the idea for
eq in the equilibrium case, the function may be interpreted
as a nonequilibrium negative dimension-less free-energy.
A set of differential equations for { O a θ } and can be derived as follows.
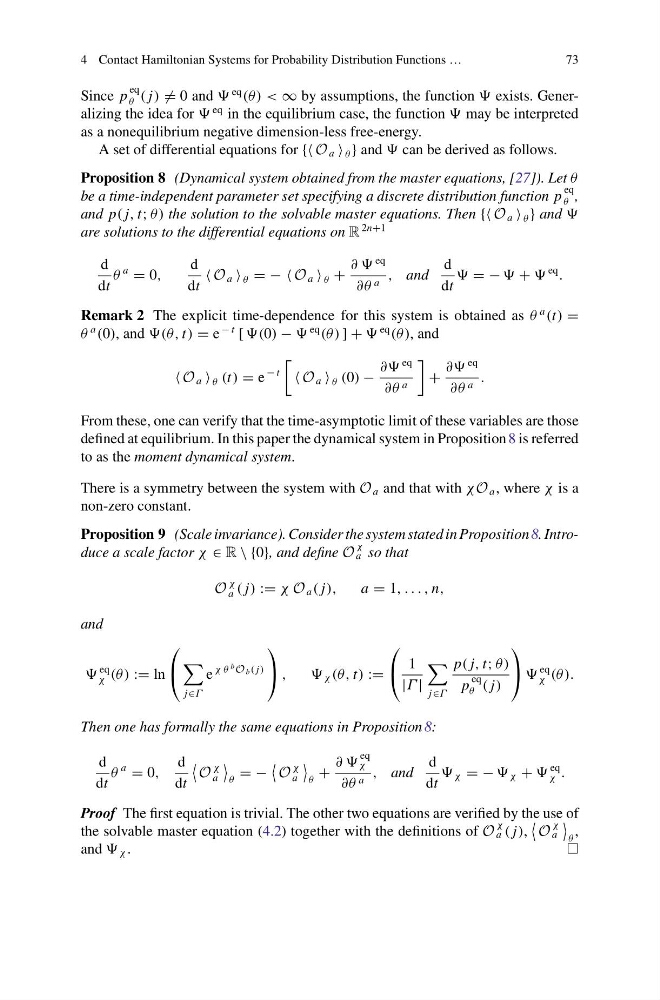
Proposition 8 (Dynamical system obtained from the master equations, [27]). Let θ
be a time-independent parameter set specifying a discrete distribution function p
eq
θ ,
and p( j, t; θ) the solution to the solvable master equations. Then { O a θ } and
are solutions to the differential equations on R
2n+1
d
dt
θ
a
= 0,
d
dt
O a θ = − O a θ +
∂ ∂
eq
∂θ a , and
d
dt
= − +
eq
.
Remark 2 The explicit time-dependence for this system is obtained as θ
a
(t) =
θ
a
(0), and t) = e
− t [ −
eq
(θ ) ] +
eq
(θ ), and
O a θ (t) = e
− t
O a θ (0) −
∂∂
eq
∂θ a
+
∂∂
eq
∂θ a .
From these, one can verify that the time-asymptotic limit of these variables are those
defined at equilibrium. In this paper the dynamical system in Proposition 8 is referred
to as the moment dynamical system.
There is a symmetry between the system with O a and that with χ O a , where χ is a
non-zero constant.
Proposition 9 (Scale invariance). Consider the system stated in Proposition 8. Introduce a scale factor χ ∈ R \ {0}, and define O
χ
a so that
O
χ
a ( j) := χ O a ( j),
a = 1, . . . , n,
and
eq
χ (θ ) := ln
⎛
⎝
j∈Γ
e
χ θ
b O b ( j)
⎞
⎠ ,
, χ (θ, t) :=
⎛
⎝ 1
|Γ |
j∈Γ
p( j, t; θ)
p
eq
θ ( j)
⎞
⎠
eq
χ (θ ).
Then one has formally the same equations in Proposition 8:
d
dt
θ
a
= 0,
d
dt
O
χ
a
θ
= −
O
χ
a
θ
+
∂ ∂
eq
χ
∂θ a , and
d
dt
χ = − χ +
eq
χ .
Proof The first equation is trivial. The other two equations are verified by the use of
the solvable master equation (4.2) together with the definitions of O
χ
a ( j),
O
χ
a
θ
,
and χ .