

283
Development of Hand Rehabilitation System for Paralysis Patients
X
Y
Y
X
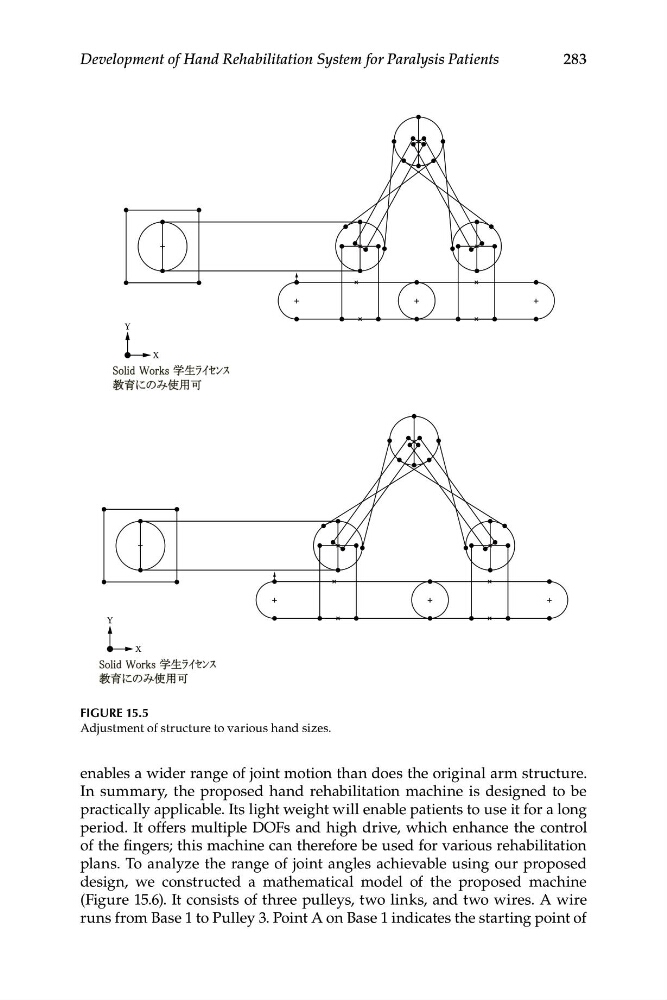
FIGURE 15.5
Adjustment of structure to various hand sizes.
enables a wider range of joint motion than does the original arm structure.
In summary, the proposed hand rehabilitation machine is designed to be
practically applicable. Its light weight will enable patients to use it for a long
period. It offers multiple DOFs and high drive, which enhance the control
of the fingers; this machine can therefore be used for various rehabilitation
plans. To analyze the range of joint angles achievable using our proposed
design, we constructed a mathematical model of the proposed machine
(Figure 15.6). It consists of three pulleys, two links, and two wires. A wire
runs from Base 1 to Pulley 3. Point A on Base 1 indicates the starting point of