

282
Biologically Inspired Robotics
X
Y
X
Y
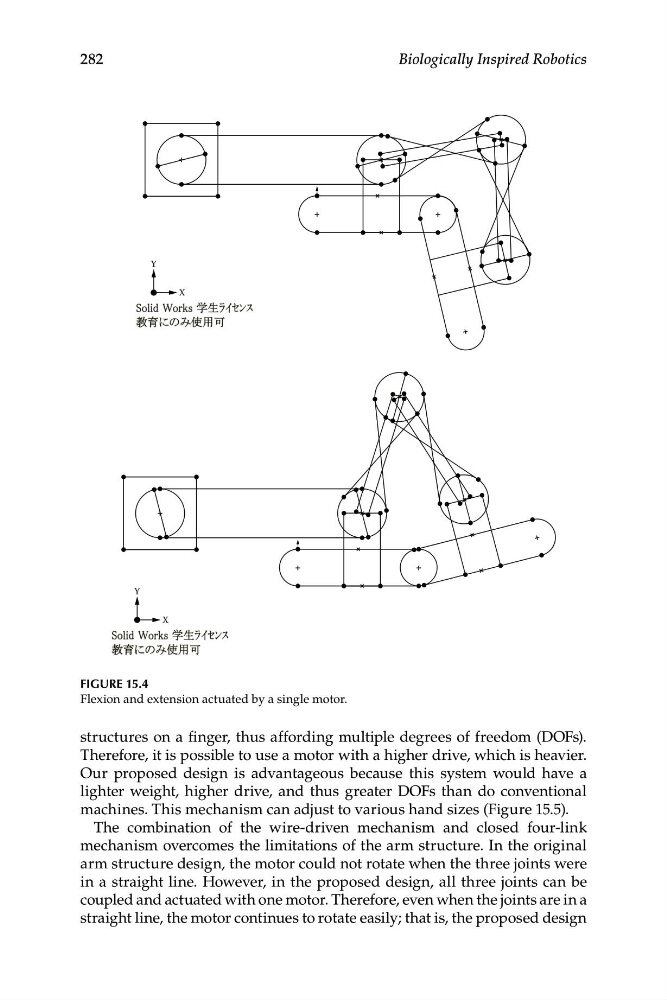
FIGURE 15.4
Flexion and extension actuated by a single motor.
structures on a finger, thus affording multiple degrees of freedom (DOFs).
Therefore, it is possible to use a motor with a higher drive, which is heavier.
Our proposed design is advantageous because this system would have a
lighter weight, higher drive, and thus greater DOFs than do conventional
machines. This mechanism can adjust to various hand sizes (Figure 15.5).
The combination of the wire-driven mechanism and closed four-link
mechanism overcomes the limitations of the arm structure. In the original
arm structure design, the motor could not rotate when the three joints were
in a straight line. However, in the proposed design, all three joints can be
coupled and actuated with one motor. Therefore, even when the joints are in a
straight line, the motor continues to rotate easily; that is, the proposed design