

252
Biologically Inspired Robotics
1
ANSYS 11.0
JUN 14 2010
21 : 47 : 28
NODAL SOLUTION
STEP = 2
SUB = 1
TIME = 2
BSUM
(AVG)
RSYS = 0
PowerGraphics
EFACET = 1
AVRES = Mat
SMX = 2.003
0
.222535
N
.445071
.667606
.890142
1.113
1.335
1.558
1.78
2.003
MX
Y
Z X
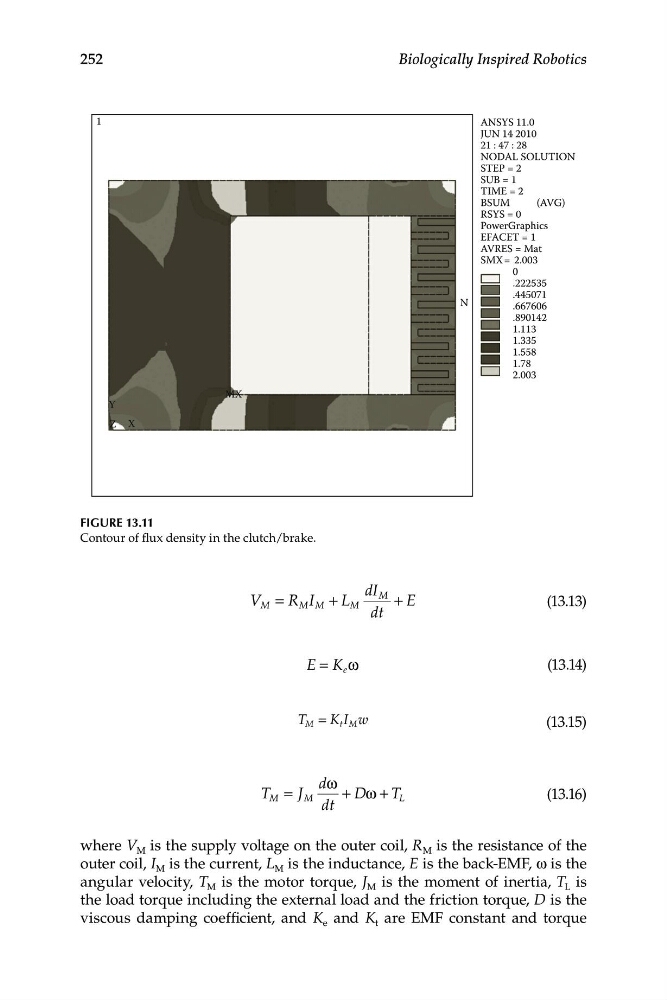
FIGURE 13.11
Contour of flux density in the clutch/brake.
dI
V M = R M I
L
M
M + M
+ E
(13.13)
dt
E K
= e ω
(13.14)
T M = K t I M w
(1 3.15)
dω
T M = J M
+ Dω + T
dt
L
(13.16)
ere V M is the supply voltage on the outer coil, R M is the resistance of the
ter coil, I M is the current, L M is the inductance, E is the back-EMF, ω is the
gular velocity, T M is the motor torque, J M is the moment of inertia, T L is
e load torque including the external load and the friction torque, D is the
cous damping coefficient, and K e and K t are EMF constant and torque
wh
ou
an
th
vis