

Multifunctional Actuators for Assistive Knee Braces
249
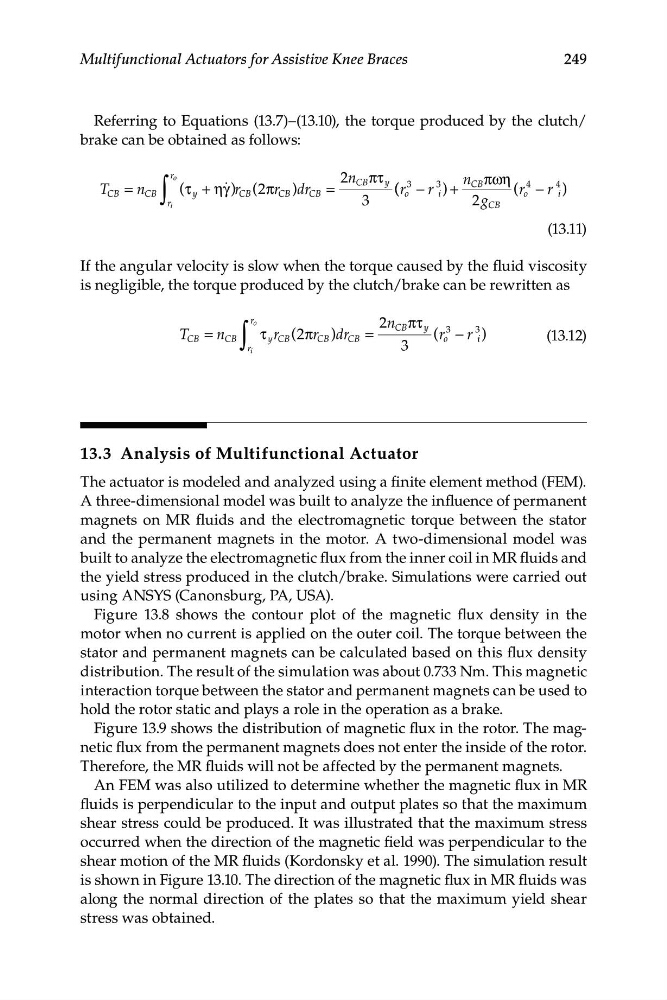
Referring to Equations (13.7)–(13.10), the torque produced by the clutch/
brake can be obtained as follows:
∫
r o
2n πτ
n πωη
T CB = n CB (τ y + ηγ q )r CB (2πr CB )dr =
CB
y
3
r
3 ) +
CB
(r
4
−
4
CB
( (r −
r )
r i
3
o
i
2g
o
i
CB
(13.11)
If the angular velocity is slow when the torque caused by the fluid viscosity
is negligible, the torque produced by the clutch/brake can be rewritten as
r o
2n CB πτ
T
y
3
3
CB = n CB ∫
τ y r CB (2πr CB )dr CB =
(r o − r i i )
(13.12)
r i
3
13.3 Analysis of Multifunctional Actuator
The actuator is modeled and analyzed using a finite element method (FEM).
A three-dimensional model was built to analyze the influence of permanent
magnets on MR fluids and the electromagnetic torque between the stator
and the permanent magnets in the motor. A two-dimensional model was
built to analyze the electromagnetic flux from the inner coil in MR fluids and
the yield stress produced in the clutch/brake. Simulations were carried out
using ANSYS (Canonsburg, PA, USA).
Figure 13.8 shows the contour plot of the magnetic flux density in the
motor when no current is applied on the outer coil. The torque between the
stator and permanent magnets can be calculated based on this flux density
distribution. The result of the simulation was about 0.733 Nm. This magnetic
interaction torque between the stator and permanent magnets can be used to
hold the rotor static and plays a role in the operation as a brake.
Figure 13.9 shows the distribution of magnetic flux in the rotor. The magnetic flux from the permanent magnets does not enter the inside of the rotor.
Therefore, the MR fluids will not be affected by the permanent magnets.
An FEM was also utilized to determine whether the magnetic flux in MR
fluids is perpendicular to the input and output plates so that the maximum
shear stress could be produced. It was illustrated that the maximum stress
occurred when the direction of the magnetic field was perpendicular to the
shear motion of the MR fluids (Kordonsky et al. 1990). The simulation result
is shown in Figure 13.10. The direction of the magnetic flux in MR fluids was
along the normal direction of the plates so that the maximum yield shear
stress was obtained.