

230
Biologically Inspired Robotics
0
Thumb
30
0
Index
30
0
V
30
0
Ok
30
0
Four
30
0
Five
30
0
Grasp
200
100
Min & max values
Average
1
2
3
4
5
6
7
8
9
10 11 12 13 14 15
Channel
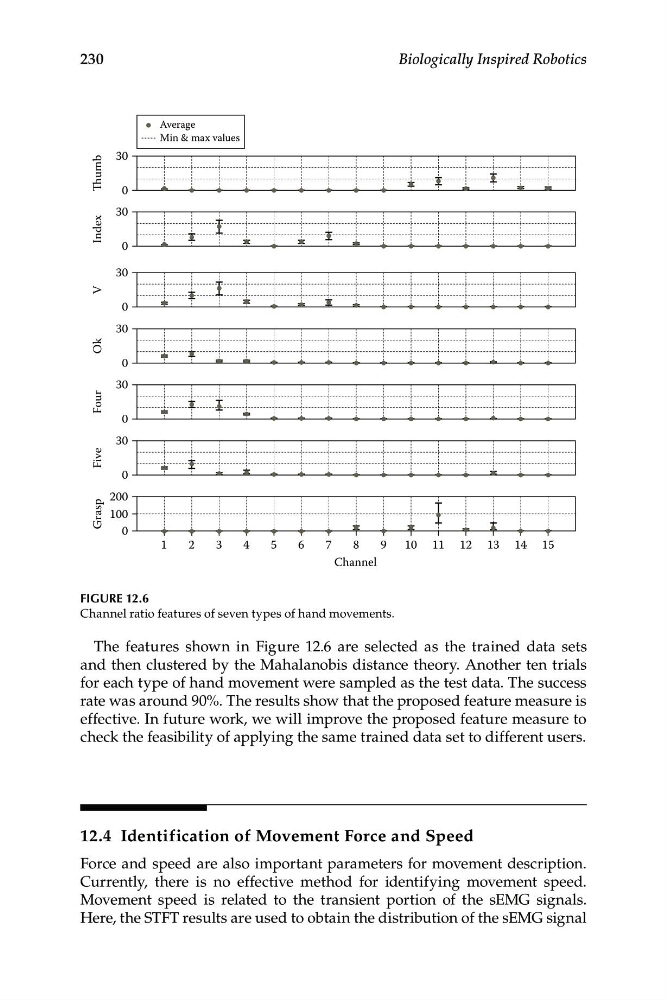
FIGURE 12.6
Channel ratio features of seven types of hand movements.
The features shown in Figure 12.6 are selected as the trained data sets
and then clustered by the Mahalanobis distance theory. Another ten trials
for each type of hand movement were sampled as the test data. The success
rate was around 90%. The results show that the proposed feature measure is
effective. In future work, we will improve the proposed feature measure to
check the feasibility of applying the same trained data set to different users.
12.4 Identification of Movement Force and Speed
Force and speed are also important parameters for movement description.
Currently, there is no effective method for identifying movement speed.
Movement speed is related to the transient portion of the sEMG signals.
Here, the STFT results are used to obtain the distribution of the sEMG signal