

103
A School of Robotic Fish for Pollution Detection in Port
Suggested
locations
for field
trials
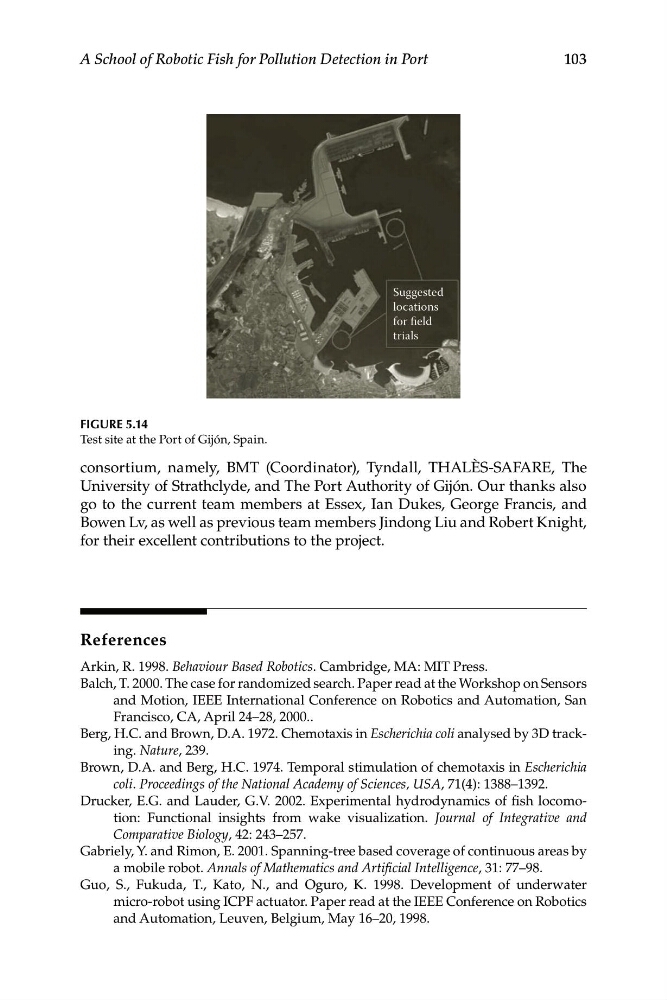
FIGURE 5.14
Test site at the Port of Gijón, Spain.
consortium, namely, BMT (Coordinator), Tyndall, THALÈS-SAFARE, The
University of Strathclyde, and The Port Authority of Gijón. Our thanks also
go to the current team members at Essex, Ian Dukes, George Francis, and
Bowen Lv, as well as previous team members Jindong Liu and Robert Knight,
for their excellent contributions to the project.
References
Arkin, R. 1998. Behaviour Based Robotics. Cambridge, MA: MIT Press.
Balch, T. 2000. The case for randomized search. Paper read at the Workshop on Sensors
and Motion, IEEE International Conference on Robotics and Automation, San
Francisco, CA, April 24–28, 2000..
Berg, H.C. and Brown, D.A. 1972. Chemotaxis in Escherichia coli analysed by 3D tracking. Nature, 239.
Brown, D.A. and Berg, H.C. 1974. Temporal stimulation of chemotaxis in Escherichia
coli. Proceedings of the National Academy of Sciences, USA, 71(4): 1388–1392.
Drucker, E.G. and Lauder, G.V. 2002. Experimental hydrodynamics of fish locomotion: Functional insights from wake visualization. Journal of Integrative and
Comparative Biology, 42: 243–257.
Gabriely, Y. and Rimon, E. 2001. Spanning-tree based coverage of continuous areas by
a mobile robot. Annals of Mathematics and Artificial Intelligence, 31: 77–98.
Guo, S., Fukuda, T., Kato, N., and Oguro, K. 1998. Development of underwater
micro-robot using ICPF actuator. Paper read at the IEEE Conference on Robotics
and Automation, Leuven, Belgium, May 16–20, 1998.