

12 The Dynamics of Eccentric Vibration Mechanism (Part 2)
181
12.5 The Numerical Study of the Dynamics
of the Mechanism
The complex dynamics of the two-piston mechanism was studied using numerical–analytical computations with the help of a software complex developed in the
Borland Developer Studio 2006 (Arkhangelskiy 2002; Kernighan and Ritchie 2016;
Stroustrup 2011). This complex allows us to compute phase trajectories, bifurcation
diagrams and regions of existence and stability of the main periodic motion modes
of the mechanism.
12.5.1 The Region of Existence and Stability of Periodic
Motions
Let us denote the region of existence and stability of periodic motions in the parameter
space through D(m 1 , m 2 ), where m 1 is the number of strokes by the first piston against
the rod,m 2 is the number of strokes by the second piston against the rod.
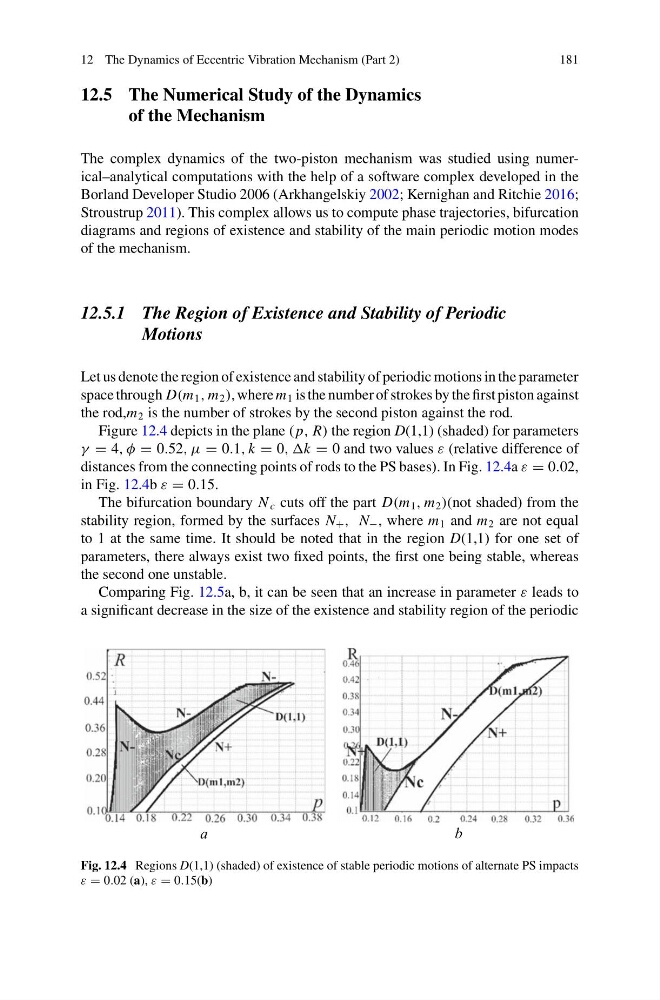
Figure 12.4 depicts in the plane ( p, R) the region D(1,1) (shaded) for parameters
γ = 4, φ = 0.52, μ = 0.1, k = 0, ,k = 0 and two values ε (relative difference of
distances from the connecting points of rods to the PS bases). In Fig. 12.4a ε = 0.02,
in Fig. 12.4b ε = 0.15.
The bifurcation boundary N c cuts off the part D(m 1 , m 2 )(not shaded) from the
stability region, formed by the surfaces N + , N − , where m 1 and m 2 are not equal
to 1 at the same time. It should be noted that in the region D(1,1) for one set of
parameters, there always exist two fixed points, the first one being stable, whereas
the second one unstable.
Comparing Fig. 12.5a, b, it can be seen that an increase in parameter ε leads to
a significant decrease in the size of the existence and stability region of the periodic
a
b
Fig. 12.4 Regions D(1,1) (shaded) of existence of stable periodic motions of alternate PS impacts
ε = 0.02 (a), ε = 0.15(b)