

12 The Dynamics of Eccentric Vibration Mechanism (Part 2)
179
where
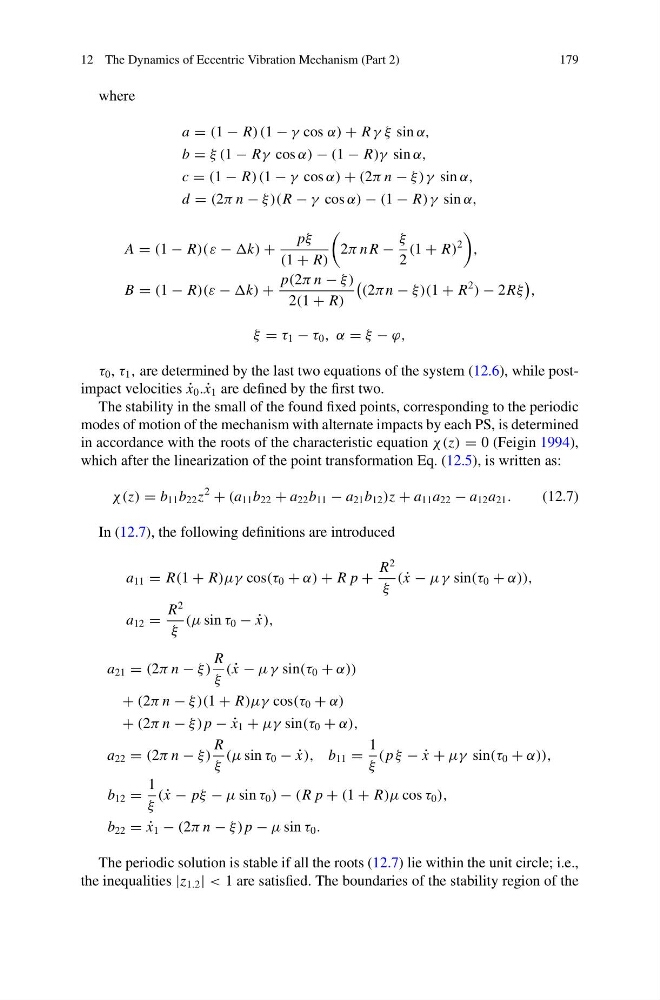
a = (1 − R)(1 − γ cos α) + R γ ξ sin α,
b = ξ (1 − Rγ cos α) − (1 − R)γ sin α,
c = (1 − R)(1 − γ cos α) + (2π n − ξ)γ sin α,
d = (2π n − ξ)(R − γ cos α) − (1 − R)γ sin α,
A = (1 − R)( ε − k) +
pξ
(1 + R)
2π n R −
ξ
2
(1 + R)
2
,
B = (1 − R)(ε − k) +
p(2π n − ξ)
2(1 + R)
(2π n − ξ)(1 + R
2
) − 2Rξ
,
ξ = τ 1 − τ 0 , α = ξ − ϕ,
τ 0 , τ 1 , are determined by the last two equations of the system (12.6), while postimpact velocities ˙
x 0 . ˙
x 1 are defined by the first two.
The stability in the small of the found fixed points, corresponding to the periodic
modes of motion of the mechanism with alternate impacts by each PS, is determined
in accordance with the roots of the characteristic equation χ(z) = 0 (Feigin 1994),
which after the linearization of the point transformation Eq. (12.5), is written as:
χ(z) = b 11 b 22 z
2
+ (a 11 b 22 + a 22 b 11 − a 21 b 12 )z + a 11 a 22 − a 12 a 21 .
(12.7)
In (12.7), the following definitions are introduced
a 11 = R(1 + R)μγ cos(τ 0 + α) + R p +
R
2
ξ
( ˙
x − μγ sin(τ 0 + α)),
a 12 =
R
2
ξ
(μ sin τ 0 − ˙
x),
a 21 = (2π n − ξ)
R
ξ
( ˙
x − μγ sin(τ 0 + α))
+ (2π n − ξ)(1 + R)μγ cos(τ 0 + α)
+ (2π n − ξ) p − ˙
x 1 + μγ sin(τ 0 + α),
a 22 = (2π n − ξ)
R
ξ
(μ sin τ 0 − ˙
x), b 11 =
1
ξ
( p ξ − ˙
x + μγ sin(τ 0 + α)),
b 12 =
1
ξ
( ˙
x − pξ − μ sin τ 0 ) − (R p + (1 + R)μ cos τ 0 ),
b 22 = ˙
x 1 − (2π n − ξ) p − μ sin τ 0 .
The periodic solution is stable if all the roots (12.7) lie within the unit circle; i.e.,
the inequalities |z 1.2 | < 1 are satisfied. The boundaries of the stability region of the