

7 Introduction to Optimisation
245
during successive iterations and a better global minima frontier can be achieved.
The algorithms than differ in the way they interact with the external population.
Representative algorithms of this class are strength Pareto evolutionary algorithm
(SPEA) [56, 57], NSGA2 [58], Pareto archived evolution strategy (PAES) [59],
Pareto envelope-based selection algorithm (PESA) [60, 61] and micro-genetic
algorithm (Micro-GA) [62, 63].
Another group of population-based algorithms not classifiable as genetic algorithms
already mentioned in the previous section gets inspired by natural phenomena such
as the cooling state of a metal or the behaviour of an ant colony in the search of food.
A corresponding reformulation of the already presented algorithms is available for
multi-objective optimisation problems. Namely, they are multi-objective simulating
annealing (MOSA) [64], multi-objective particle swarm optimisation (MOPSO)
[65] and multi-objective ant colony optimisation (MOACO) [66].
7.2.4 Optimal Control
The general statement of an optimal control problem (OCP) requires the definition
of [67]:
• The mathematical model of the dynamic system to control
Usually it is described by a system of ordinary differential equations (ODEs)
in the form ˙
x = f(t, x(t), u(t)). The independent variable has been indicated by
t, usually appointed as time, but there is no restriction on its choice. The variables
x i in the vector of x are usually called state variables, while u j in the vector u
are the control variables.
• The performance index J to be minimised (or equivalently maximised)
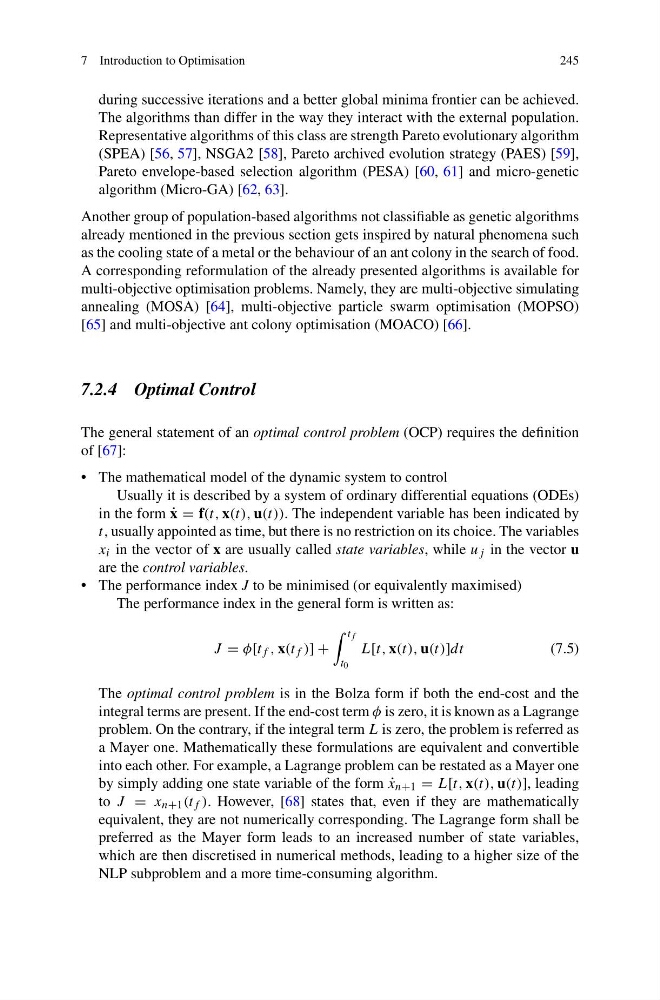
The performance index in the general form is written as:
J = φ[t f , x(t f )] +
t f
t 0
L[t, x(t), u(t)]dt
(7.5)
The optimal control problem is in the Bolza form if both the end-cost and the
integral terms are present. If the end-cost term φ is zero, it is known as a Lagrange
problem. On the contrary, if the integral term L is zero, the problem is referred as
a Mayer one. Mathematically these formulations are equivalent and convertible
into each other. For example, a Lagrange problem can be restated as a Mayer one
by simply adding one state variable of the form ˙
x n+1 = L[t, x(t), u(t)], leading
to J = x n+1 (t f ). However, [68] states that, even if they are mathematically
equivalent, they are not numerically corresponding. The Lagrange form shall be
preferred as the Mayer form leads to an increased number of state variables,
which are then discretised in numerical methods, leading to a higher size of the
NLP subproblem and a more time-consuming algorithm.