

5.4 Space-Time Reference Based on General Relativity
303
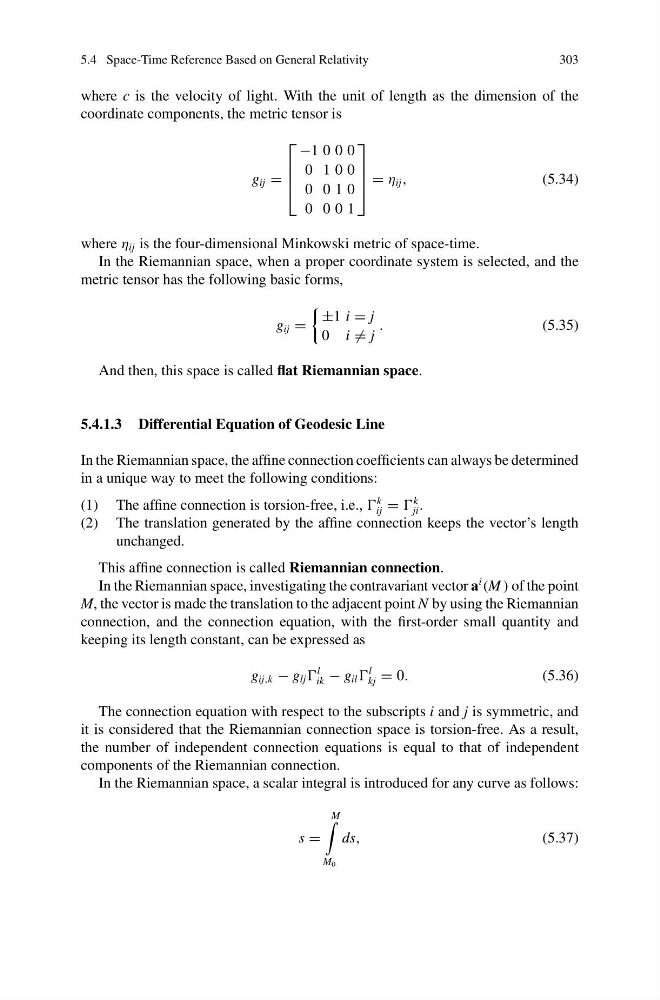
where c is the velocity of light. With the unit of length as the dimension of the
coordinate components, the metric tensor is
g ij =
⎡
⎢
⎢
⎣
−1 0 0 0
0 1 0 0
0 0 1 0
0 0 0 1
⎤
⎥
⎥
⎦ = η ij ,
(5.34)
where η ij is the four-dimensional Minkowski metric of space-time.
In the Riemannian space, when a proper coordinate system is selected, and the
metric tensor has the following basic forms,
g ij =
±1 i = j
0 i = j
.
(5.35)
And then, this space is called flat Riemannian space.
5.4.1.3 Differential Equation of Geodesic Line
In the Riemannian space, the affine connection coefficients can always be determined
in a unique way to meet the following conditions:
(1) The affine connection is torsion-free, i.e.,
k
ij =
k
ji .
(2) The translation generated by the affine connection keeps the vector’s length
unchanged.
This affine connection is called Riemannian connection.
In the Riemannian space, investigating the contravariant vector a
i
(M ) of the point
M, the vector is made the translation to the adjacent point N by using the Riemannian
connection, and the connection equation, with the first-order small quantity and
keeping its length constant, can be expressed as
g ij,k − g lj
l
ik − g il
l
kj = 0.
(5.36)
The connection equation with respect to the subscripts i and j is symmetric, and
it is considered that the Riemannian connection space is torsion-free. As a result,
the number of independent connection equations is equal to that of independent
components of the Riemannian connection.
In the Riemannian space, a scalar integral is introduced for any curve as follows:
s =
M
M 0
ds,
(5.37)