

302
5 X-ray Pulsar-Based Navigation: Theories and Experiments
Then the vector space is known as Riemannian space. The quadratic form ds
2
is the line element of the Riemannian space, and g ij is the metric tensor of the
Riemannian space. In this way, the differential form of the arc length of a curve can
be defined as
ds =
g ij dx i dx j .
(5.28)
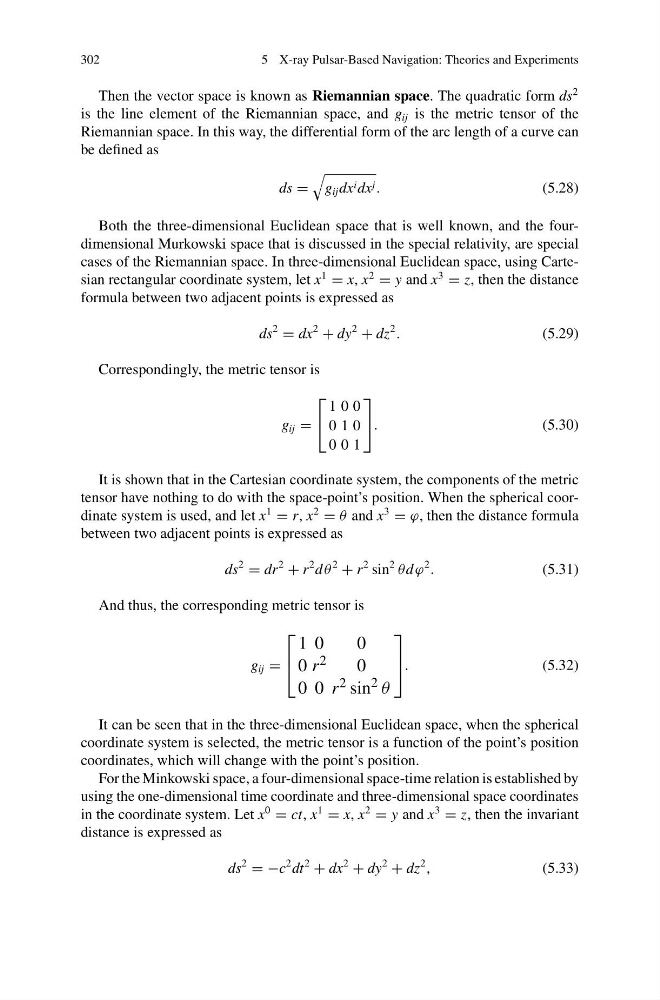
Both the three-dimensional Euclidean space that is well known, and the fourdimensional Murkowski space that is discussed in the special relativity, are special
cases of the Riemannian space. In three-dimensional Euclidean space, using Cartesian rectangular coordinate system, let x
1
= x, x
2
= y and x
3
= z, then the distance
formula between two adjacent points is expressed as
ds
2
= dx
2
+ dy
2
+ dz
2
.
(5.29)
Correspondingly, the metric tensor is
g ij =
⎡
⎣
1 0 0
0 1 0
0 0 1
⎤
⎦ .
(5.30)
It is shown that in the Cartesian coordinate system, the components of the metric
tensor have nothing to do with the space-point’s position. When the spherical coordinate system is used, and let x
1
= r, x
2
= θ and x
3
= ϕ, then the distance formula
between two adjacent points is expressed as
ds
2
= dr
2
+ r
2 d θ
2
+ r
2 sin
2
θ d ϕ
2
.
(5.31)
And thus, the corresponding metric tensor is
g ij =
⎡
⎢
⎣
1 0
0
0 r 2
0
0 0 r 2 sin 2 θ
⎤
⎥
⎦.
(5.32)
It can be seen that in the three-dimensional Euclidean space, when the spherical
coordinate system is selected, the metric tensor is a function of the point’s position
coordinates, which will change with the point’s position.
For the Minkowski space, a four-dimensional space-time relation is established by
using the one-dimensional time coordinate and three-dimensional space coordinates
in the coordinate system. Let x
0
= ct, x
1
= x, x
2
= y and x
3
= z, then the invariant
distance is expressed as
ds
2
= −c
2 dt
2
+ dx
2
+ dy
2
+ dz
2
,
(5.33)