

E1C03 09/14/2010
15:24:52 Page 81
point. The motion sensed by the passengers, y(t), is a basis for the ride quality and can be described
by a waveform that depends on the input from the road and the behavior of the suspension. An
engineer must anticipate the form of the input signals so as to design the suspension to attain a
desirable output signal.
Measurement systems play a key role in documenting ride quality. But just as the road and car
interact to provide ride quality, the input signal and the measurement system interact in creating the
output signal. In many situations, the goal of the measurement is to deduce the input signal based on
the output signal. Either way, we see that it is important to understand how a measurement system
responds to different forms of input signals.
The general behavior of measurement systems for a few common inputs defines, for the most part, the
input–output signal relationships necessary to correctly interpret measured signals. We will show that only
a few measurement system characteristics (specifications) are needed to predict the system response.
With the previous discussion in mind, consider that the primary task of a measurement system is
to sense an input signal and to translate that information into a readily understandable and
quantifiable output form. We can reason that a measurement system performs some mathematical
operation on a sensed input. In fact, a general measurement system can be represented by a
differential equation that describes the operation that a measurement system performs on the input
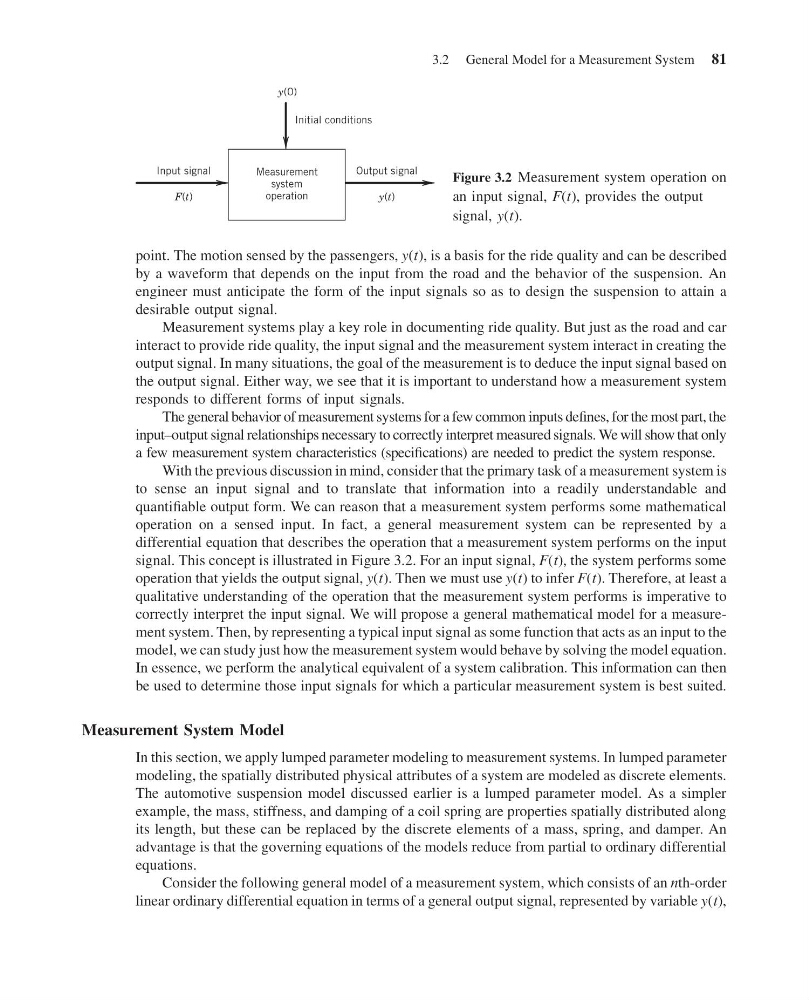
signal. This concept is illustrated in Figure 3.2. For an input signal, F(t), the system performs some
operation that yields the output signal, y(t). Then we must use y(t) to infer F(t). Therefore, at least a
qualitative understanding of the operation that the measurement system performs is imperative to
correctly interpret the input signal. We will propose a general mathematical model for a measurement system. Then, by representing a typical input signal as some function that acts as an input to the
model, we can study just how the measurement system would behave by solving the model equation.
In essence, we perform the analytical equivalent of a system calibration. This information can then
be used to determine those input signals for which a particular measurement system is best suited.
Measurement System Model
In this section, we apply lumped parameter modeling to measurement systems. In lumped parameter
modeling, the spatially distributed physical attributes of a system are modeled as discrete elements.
The automotive suspension model discussed earlier is a lumped parameter model. As a simpler
example, the mass, stiffness, and damping of a coil spring are properties spatially distributed along
its length, but these can be replaced by the discrete elements of a mass, spring, and damper. An
advantage is that the governing equations of the models reduce from partial to ordinary differential
equations.
Consider the following general model of a measurement system, which consists of an nth-order
linear ordinary differential equation in terms of a general output signal, represented by variable y(t),
y(t)
F(t)
y(0)
l
a
n
g
i
s
t
u
p
t
u
O
l
a
n
g
i
s
t
u
p
n
I
Initial conditions
Measurement
system
operation
Figure 3.2 Measurement system operation on
an input signal, F(t), provides the output
signal, y(t).
3.2 General Model for a Measurement System 81