

E1C12 09/14/2010
13:54:15 Page 556
Proportional Integral-Derivative Control
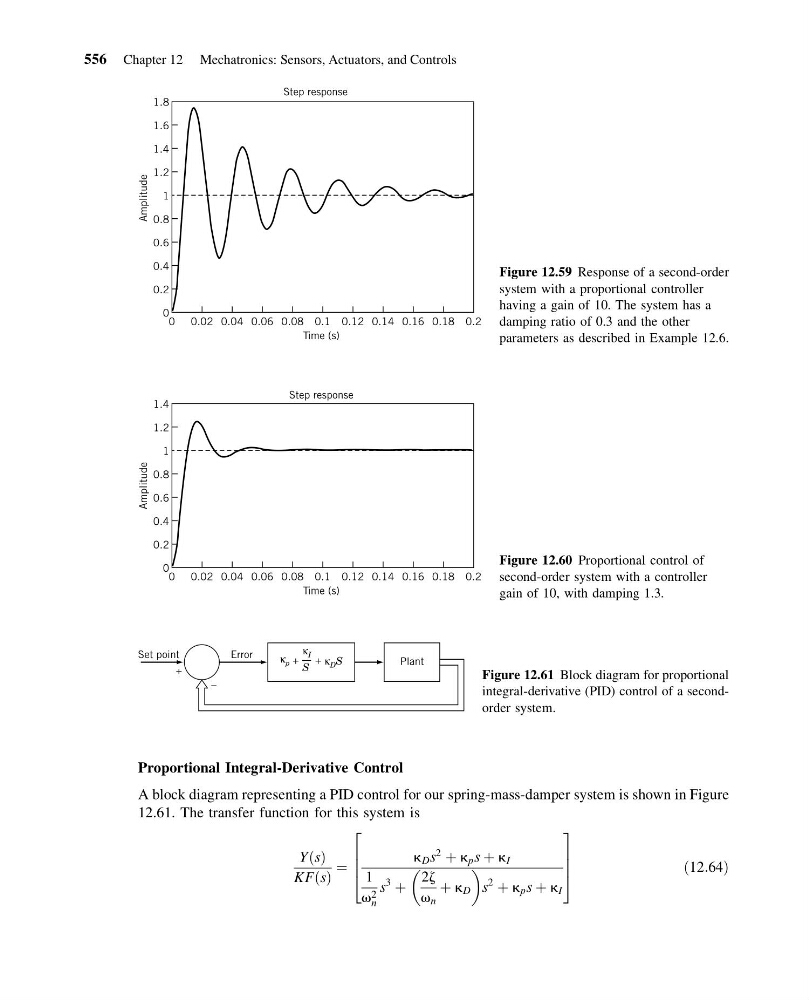
A block diagram representing a PID control for our spring-mass-damper system is shown in Figure
12.61. The transfer function for this system is
Y s
ð Þ
KF s
ð Þ
¼
k D s
2
þ k p s þ k I
1
v 2
n
s
3
þ
2z
v n
þ k D
s
2
þ k p s þ k I
2
6
6
4
3
7
7
5
ð12:64Þ
0
0.2
0.4
0.6
0.8
1
1.2
1.4
1.6
1.8
0.2
0.18
0.16
0.14
0.12
0.1
0.08
0.06
0.04
0.02
0
Time (s)
Step response
Amplitude
Figure 12.59 Response of a second-order
system with a proportional controller
having a gain of 10. The system has a
damping ratio of 0.3 and the other
parameters as described in Example 12.6.
0
0.2
0.4
0.6
0.8
1
1.2
1.4
0.2
0.18
0.16
0.14
0.12
0.1
0.08
0.06
0.04
0.02
0
Time (s)
Step response
Amplitude
Figure 12.60 Proportional control of
second-order system with a controller
gain of 10, with damping 1.3.
+
+
+
–
Plant
Error
Set point
κ p
κ D S
S
κ I
Figure 12.61 Block diagram for proportional
integral-derivative (PID) control of a secondorder system.
556 Chapter 12 Mechatronics: Sensors, Actuators, and Controls