

E1C12 09/14/2010
13:54:14 Page 544
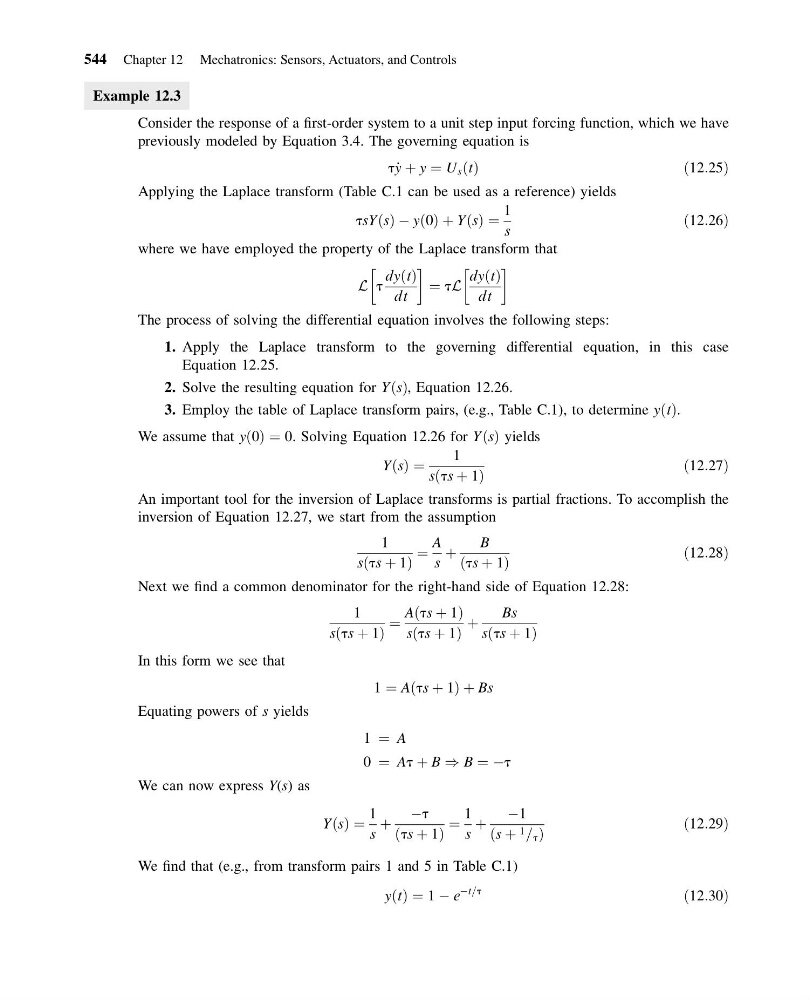
Example 12.3
Consider the response of a first-order system to a unit step input forcing function, which we have
previously modeled by Equation 3.4. The governing equation is
t_ y þ y ¼ U s t
ð Þ
ð12:25Þ
Applying the Laplace transform (Table C.1 can be used as a reference) yields
tsY s
ð Þ À y 0
ð Þ þ Y s
ð Þ ¼
1
s
ð12:26Þ
where we have employed the property of the Laplace transform that
L t
dy t
ð Þ
dt
!
¼ tL
dy t
ð Þ
dt
!
The process of solving the differential equation involves the following steps:
1. Apply the Laplace transform to the governing differential equation, in this case
Equation 12.25.
2. Solve the resulting equation for Y s
ð Þ, Equation 12.26.
3. Employ the table of Laplace transform pairs, (e.g., Table C.1), to determine y t
ð Þ.
We assume that y 0
ð Þ ¼ 0. Solving Equation 12.26 for Y s
ð Þ yields
Y s
ð Þ ¼
1
s ts þ 1
ð
Þ
ð12:27Þ
An important tool for the inversion of Laplace transforms is partial fractions. To accomplish the
inversion of Equation 12.27, we start from the assumption
1
s ts þ 1
ð
Þ
¼
A
s
þ
B
ts þ 1
ð
Þ
ð12:28Þ
Next we find a common denominator for the right-hand side of Equation 12.28:
1
s ts þ 1
ð
Þ
¼
A ts þ 1
ð
Þ
s ts þ 1
ð
Þ
þ
Bs
s ts þ 1
ð
Þ
In this form we see that
1 ¼ A ts þ 1
ð
ÞþBs
Equating powers of s yields
1 ¼ A
0 ¼ At þ B ) B ¼ Àt
We can now express Y(s) as
Y s
ð Þ ¼
1
s
þ
Àt
ts þ 1
ð
Þ
¼
1
s
þ
À1
s þ 1 t
= Þ
ð
ð12:29Þ
We find that (e.g., from transform pairs 1 and 5 in Table C.1)
y t
ð Þ ¼ 1 À e
Àt=t
ð12:30Þ
544 Chapter 12 Mechatronics: Sensors, Actuators, and Controls