

E1C12 09/14/2010
13:54:9 Page 514
FIND Values of v n , z, k, m, and c to yield a measurement with less than 5% dynamic error.
Examine the phase response of the system.
SOLUTION Numerous combinations of the mass, spring constant, and damping coefficient
would yield a workable design. Let’s choose m ¼ 0.05 lb m (22.7 g) and z ¼ 0.7. We know that for a
spring-mass-damper system
v ¼
ffiffiffiffi
k
m
r
c c ¼ 2
ffiffiffiffiffiffi ffi
km
p
where c c is the critical damping coefficient. With z ¼ c=c c ¼ 0:7, the damping coefficient, c, is
found as
c ¼ 2 0:7
ð Þ
ffiffiffiffiffiffi ffi
km
p
We can now examine the values of y r
ð Þ max =A and the phase angle, f, for z ¼ 0:7. The largest
magnitude in Equation 12.6 occurs when cos vt À f
ð
Þ= 1, so
y r
ð Þ max =A ¼
v=v n
ð
Þ
2
1 À v=v n
ð
Þ
2
h
i 2 þ 2z v=v n
ð
Þ
½
2
&
' 1=2
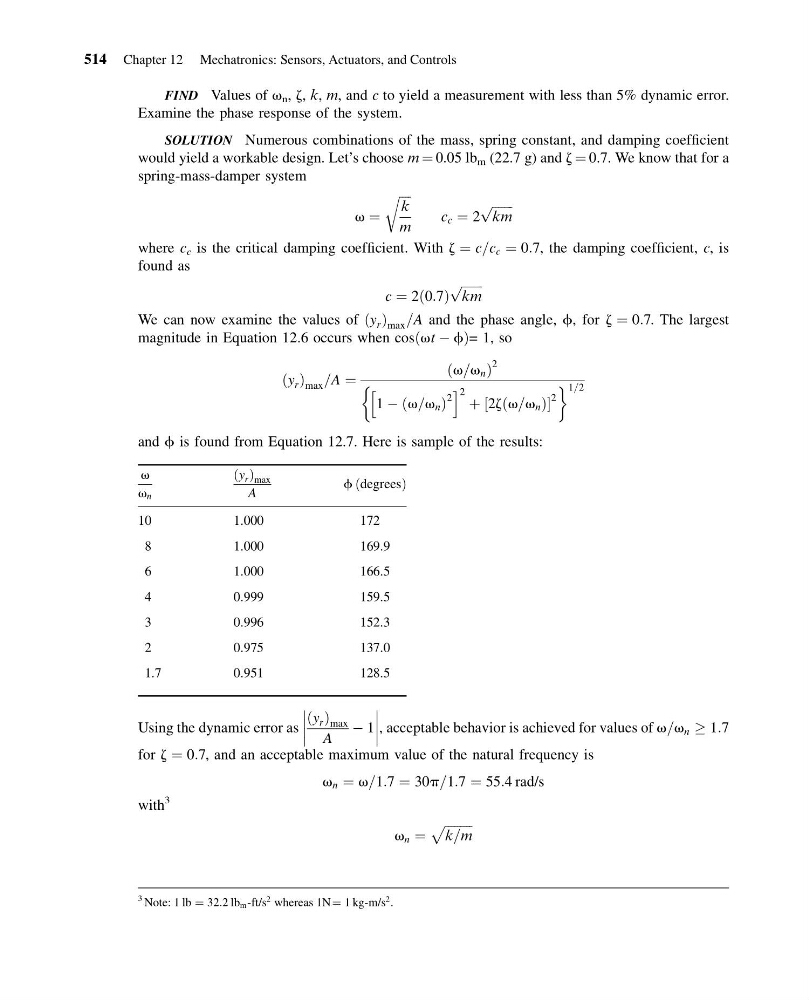
and f is found from Equation 12.7. Here is sample of the results:
v
v n
y r
ð Þ max
A
f ðdegreesÞ
10
1.000
172
8
1.000
169.9
6
1.000
166.5
4
0.999
159.5
3
0.996
152.3
2
0.975
137.0
1.7
0.951
128.5
Using the dynamic error as
y r
ð Þ max
A
À 1
, acceptable behavior is achieved for values of v=v n ! 1:7
for z ¼ 0:7, and an acceptable maximum value of the natural frequency is
v n ¼ v=1:7 ¼ 30p=1:7 ¼ 55:4 rad/s
with
3
v n ¼
ffiffiffiffiffiffiffiffiffi
k=m
p
3 Note: 1 lb ¼ 32:2 lb m -ft/s
2 whereas 1N ¼ 1 kg-m/s
2 .
514 Chapter 12 Mechatronics: Sensors, Actuators, and Controls