

666
G Hamiltonian Mechanics
and
∂L
∂q k
=
∂T
∂q k
−
∂V
∂q k
=
∂T
∂q k
+ F k
(G.2.15)
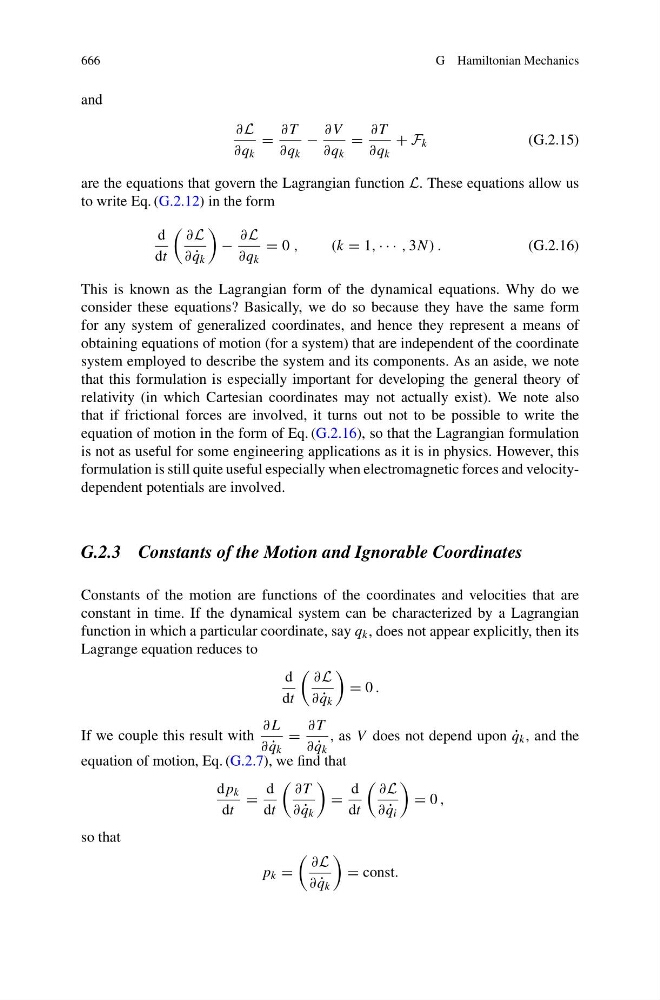
are the equations that govern the Lagrangian function L. These equations allow us
to write Eq. (G.2.12) in the form
d
dt
∂L
∂ ˙
q k
−
∂L
∂q k
= 0 ,
(k = 1, · · · , 3N) .
(G.2.16)
This is known as the Lagrangian form of the dynamical equations. Why do we
consider these equations? Basically, we do so because they have the same form
for any system of generalized coordinates, and hence they represent a means of
obtaining equations of motion (for a system) that are independent of the coordinate
system employed to describe the system and its components. As an aside, we note
that this formulation is especially important for developing the general theory of
relativity (in which Cartesian coordinates may not actually exist). We note also
that if frictional forces are involved, it turns out not to be possible to write the
equation of motion in the form of Eq. (G.2.16), so that the Lagrangian formulation
is not as useful for some engineering applications as it is in physics. However, this
formulation is still quite useful especially when electromagnetic forces and velocitydependent potentials are involved.
G.2.3 Constants of the Motion and Ignorable Coordinates
Constants of the motion are functions of the coordinates and velocities that are
constant in time. If the dynamical system can be characterized by a Lagrangian
function in which a particular coordinate, say q k , does not appear explicitly, then its
Lagrange equation reduces to
d
dt
∂L
∂ ˙
q k
= 0 .
If we couple this result with
∂L
∂ ˙
q k
=
∂T
∂ ˙
q k
, as V does not depend upon ˙
q k , and the
equation of motion, Eq. (G.2.7), we find that
dp k
dt
=
d
dt
∂T
∂ ˙
q k
=
d
dt
∂L
∂ ˙
q i
= 0 ,
so that
p k =
∂L
∂ ˙
q k
= const.