

where B gt represents the target bounding box position in the video frame and B t
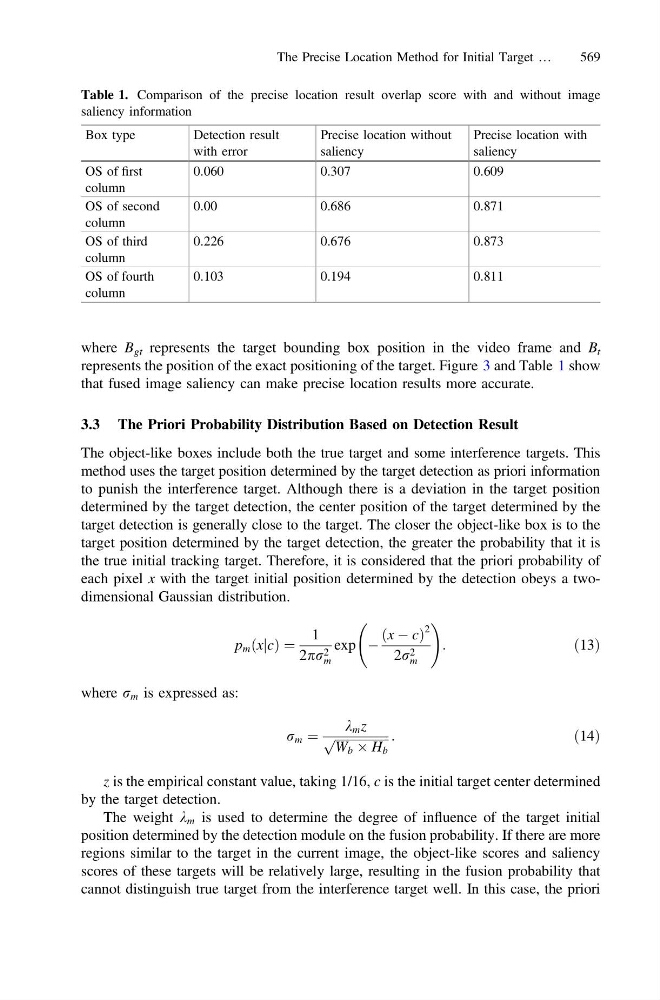
represents the position of the exact positioning of the target. Figure 3 and Table 1 show
that fused image saliency can make precise location results more accurate.
3.3 The Priori Probability Distribution Based on Detection Result
The object-like boxes include both the true target and some interference targets. This
method uses the target position determined by the target detection as priori information
to punish the interference target. Although there is a deviation in the target position
determined by the target detection, the center position of the target determined by the
target detection is generally close to the target. The closer the object-like box is to the
target position determined by the target detection, the greater the probability that it is
the true initial tracking target. Therefore, it is considered that the priori probability of
each pixel x with the target initial position determined by the detection obeys a twodimensional Gaussian distribution.
p m xjc
ð Þ ¼
1
2pr 2
m
exp À
x À c
ð
Þ
2
2r 2
m
!
:
ð13Þ
where r m is expressed as:
r m ¼
k m z
ffiffiffiffiffiffiffiffiffiffiffiffiffiffiffiffiffi ffi
W b  H b
p
:
ð14Þ
z is the empirical constant value, taking 1/16, c is the initial target center determined
by the target detection.
The weight k m is used to determine the degree of influence of the target initial
position determined by the detection module on the fusion probability. If there are more
regions similar to the target in the current image, the object-like scores and saliency
scores of these targets will be relatively large, resulting in the fusion probability that
cannot distinguish true target from the interference target well. In this case, the priori
Table 1. Comparison of the precise location result overlap score with and without image
saliency information
Box type
Detection result
with error
Precise location without
saliency
Precise location with
saliency
OS of first
column
0.060
0.307
0.609
OS of second
column
0.00
0.686
0.871
OS of third
column
0.226
0.676
0.873
OS of fourth
column
0.103
0.194
0.811
The Precise Location Method for Initial Target …
569